Justin Park

Mechanical Engineer | UAV Systems | Robotics | Systems Integration

I'm pursuing my M.S. in Mechanical Engineering at Georgia Tech, with a focus on UAVs, robotics, and systems integration. My work combines mechanical design, fabrication, and testing of electromechanical hardware.

This website is a work in progress. Projects and descriptions are still being added and refined.

Georgia Institute of TechnologyM.S. Mechanical Engineering · Georgia TechExpected May 2027B.S. Mechanical Engineering · Georgia TechGraduated May 2026
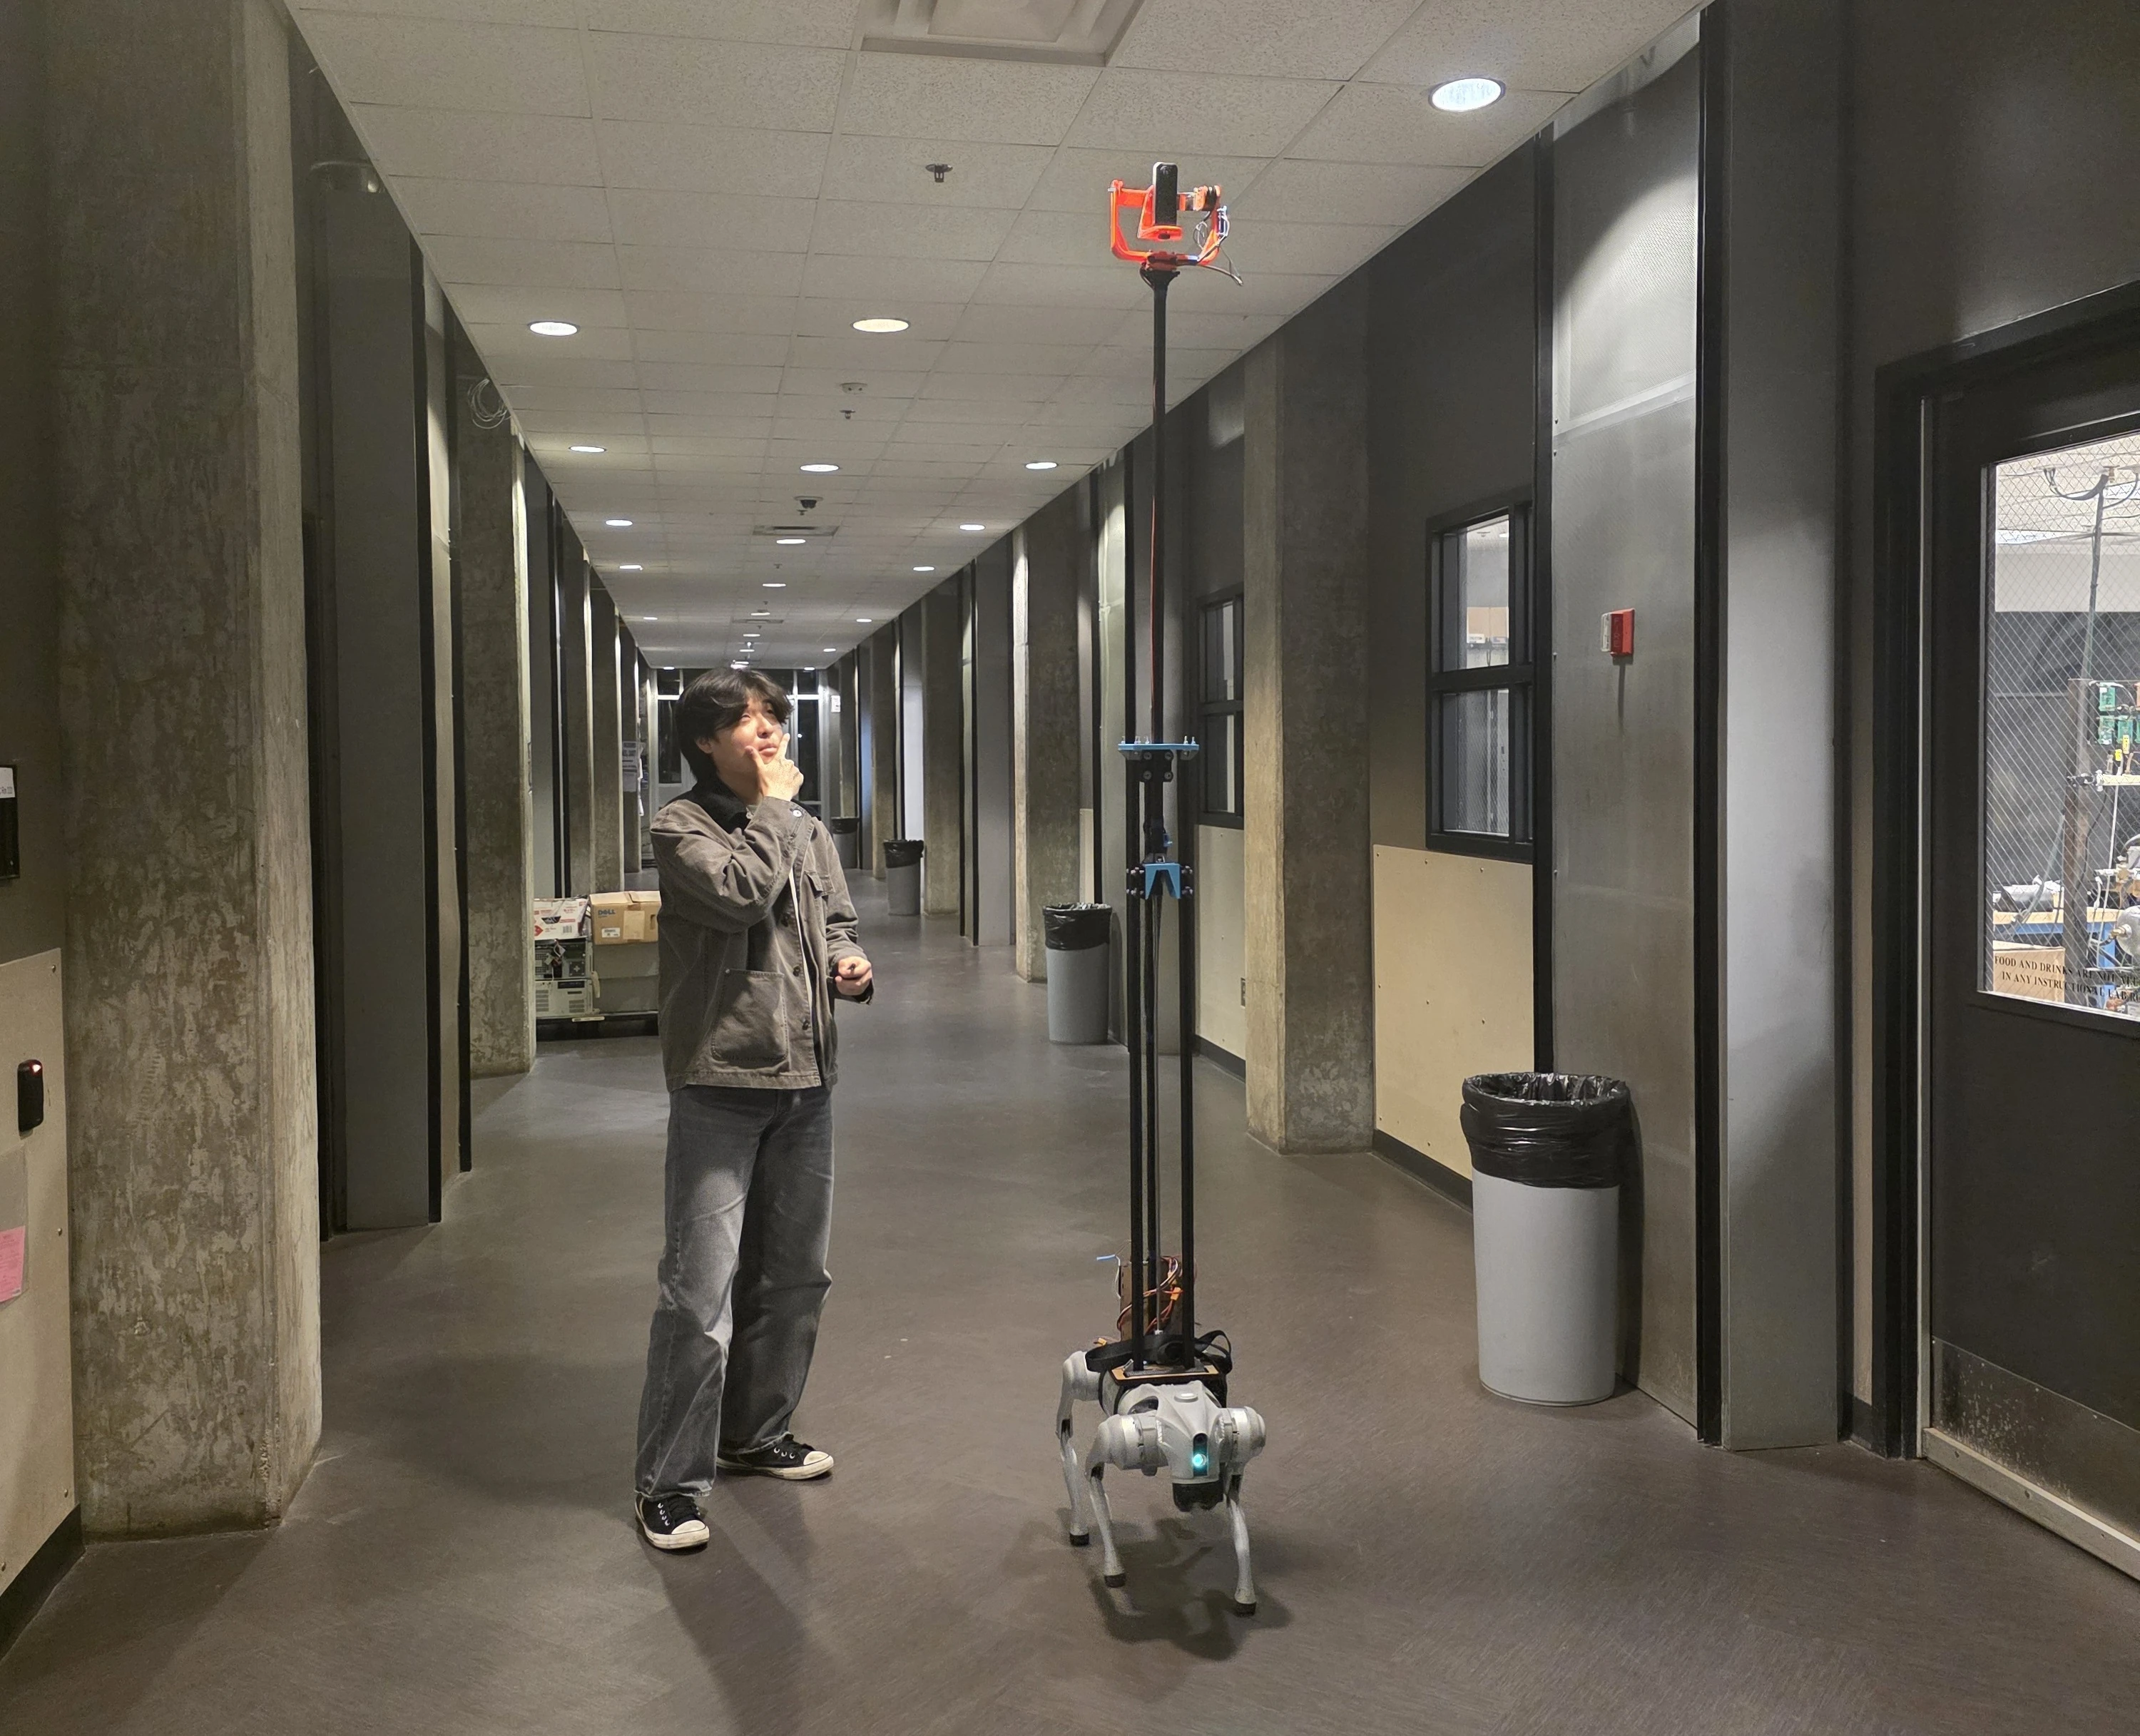
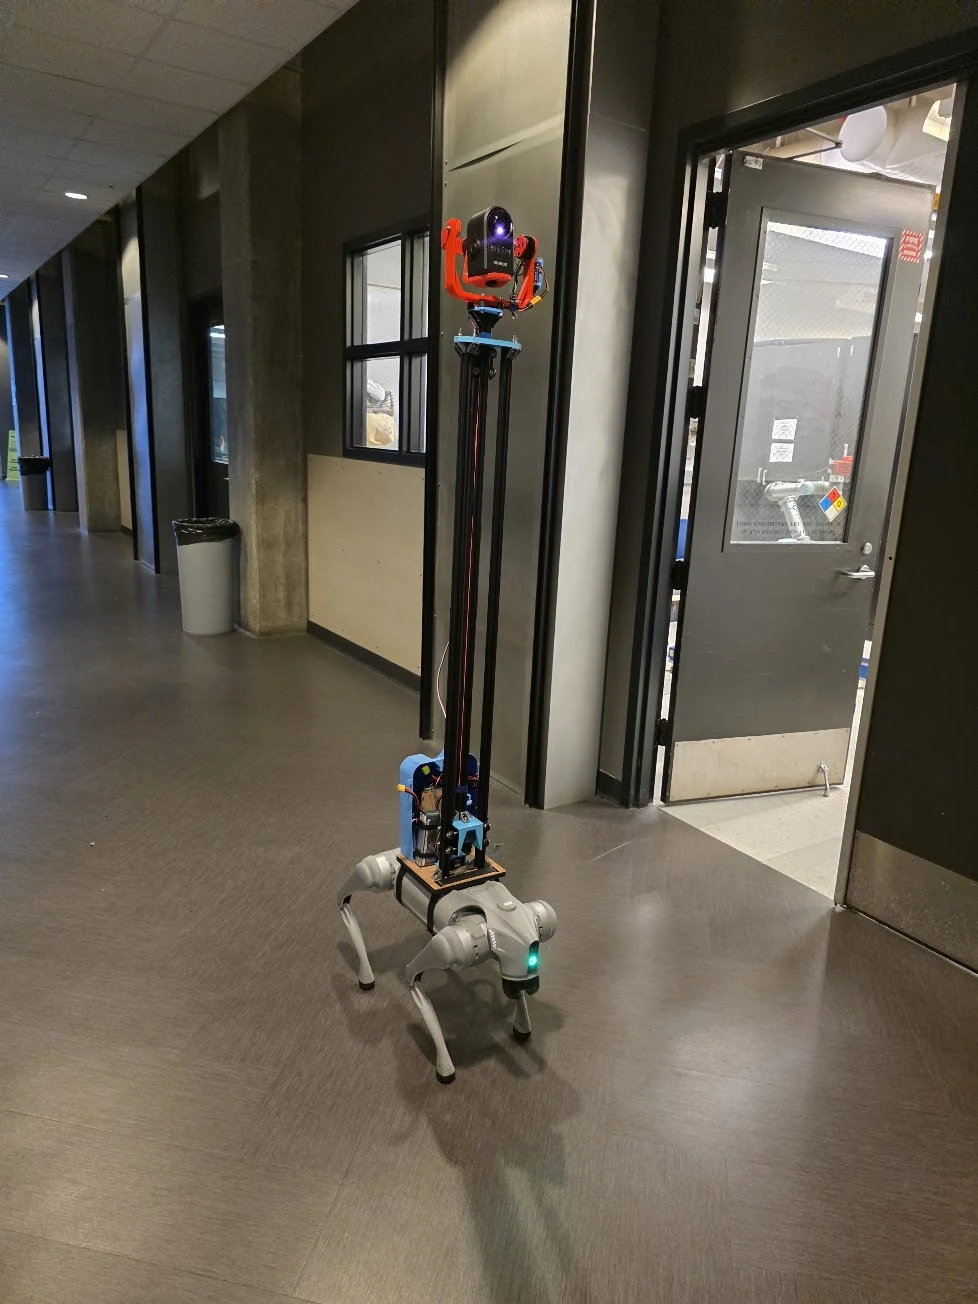
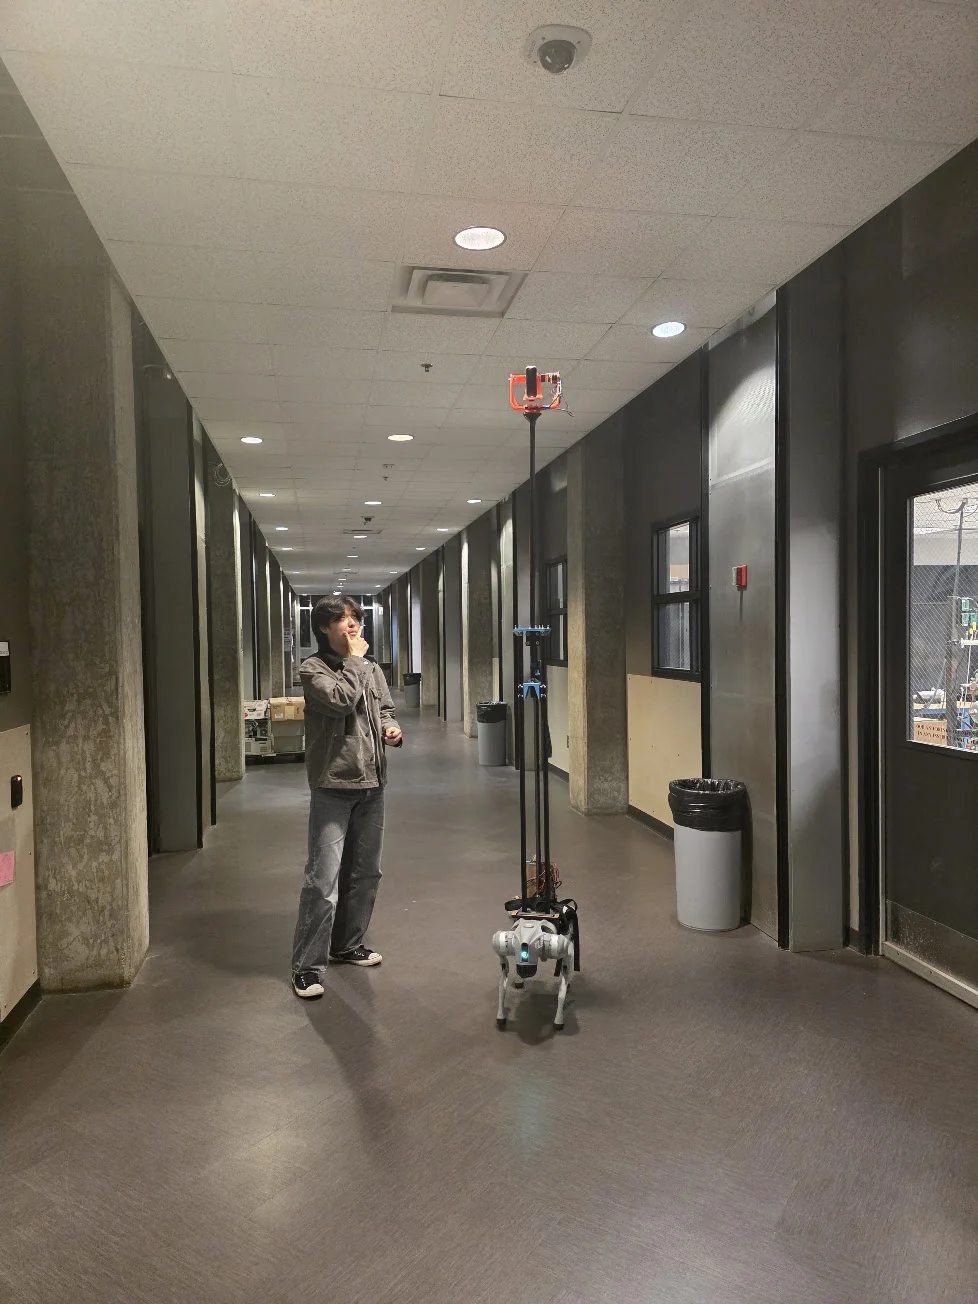
Justin Park beside the completed camera rig mounted on a quadruped robot in a hallway
Quadruped camera payloadCapstone · Fall 2025

Selected projects

Aircraft development, robotic payloads, motion control, and professional UAV integration.

All projects
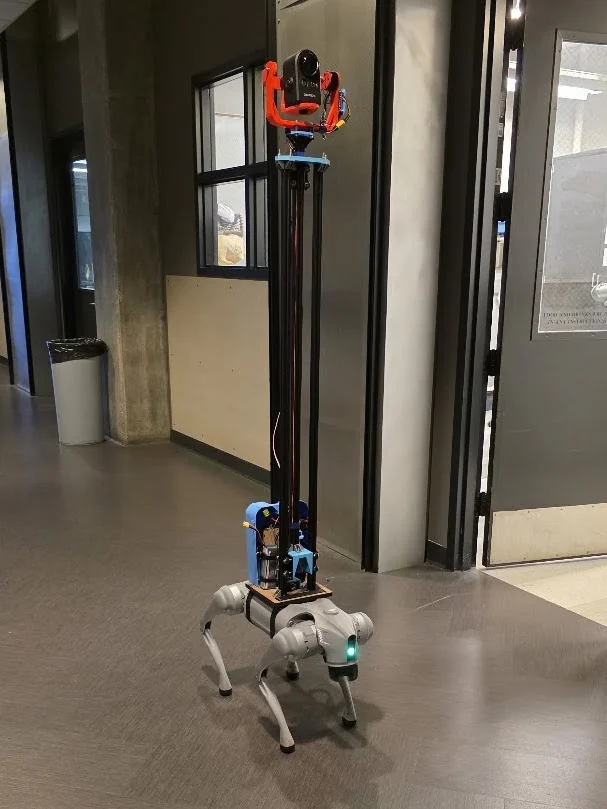
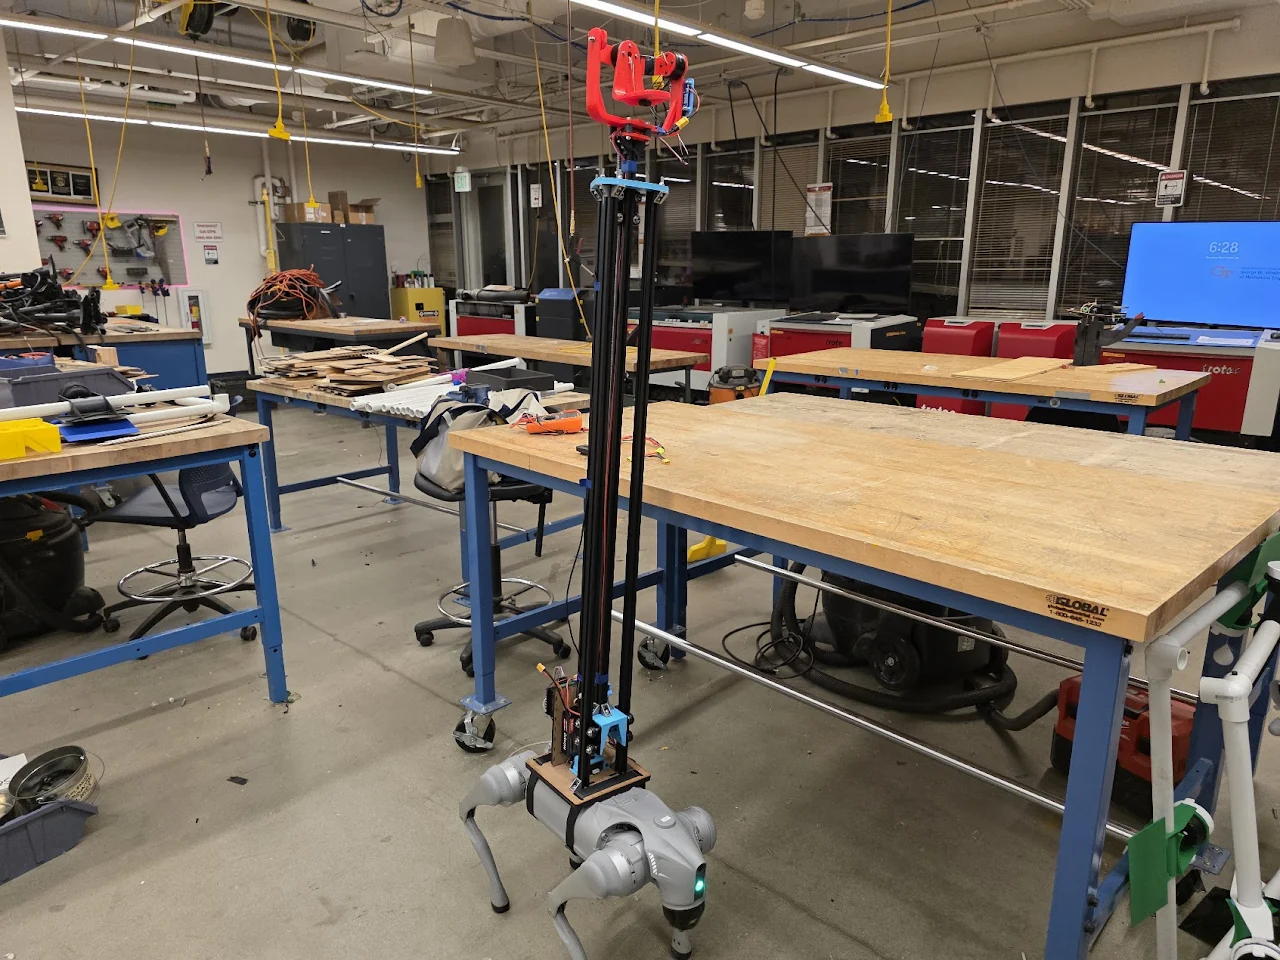
Completed height-adjustable camera rig mounted on a Unitree quadruped robot in a hallway
Team capstone · Aug–Dec 2025

Stabilized camera rig

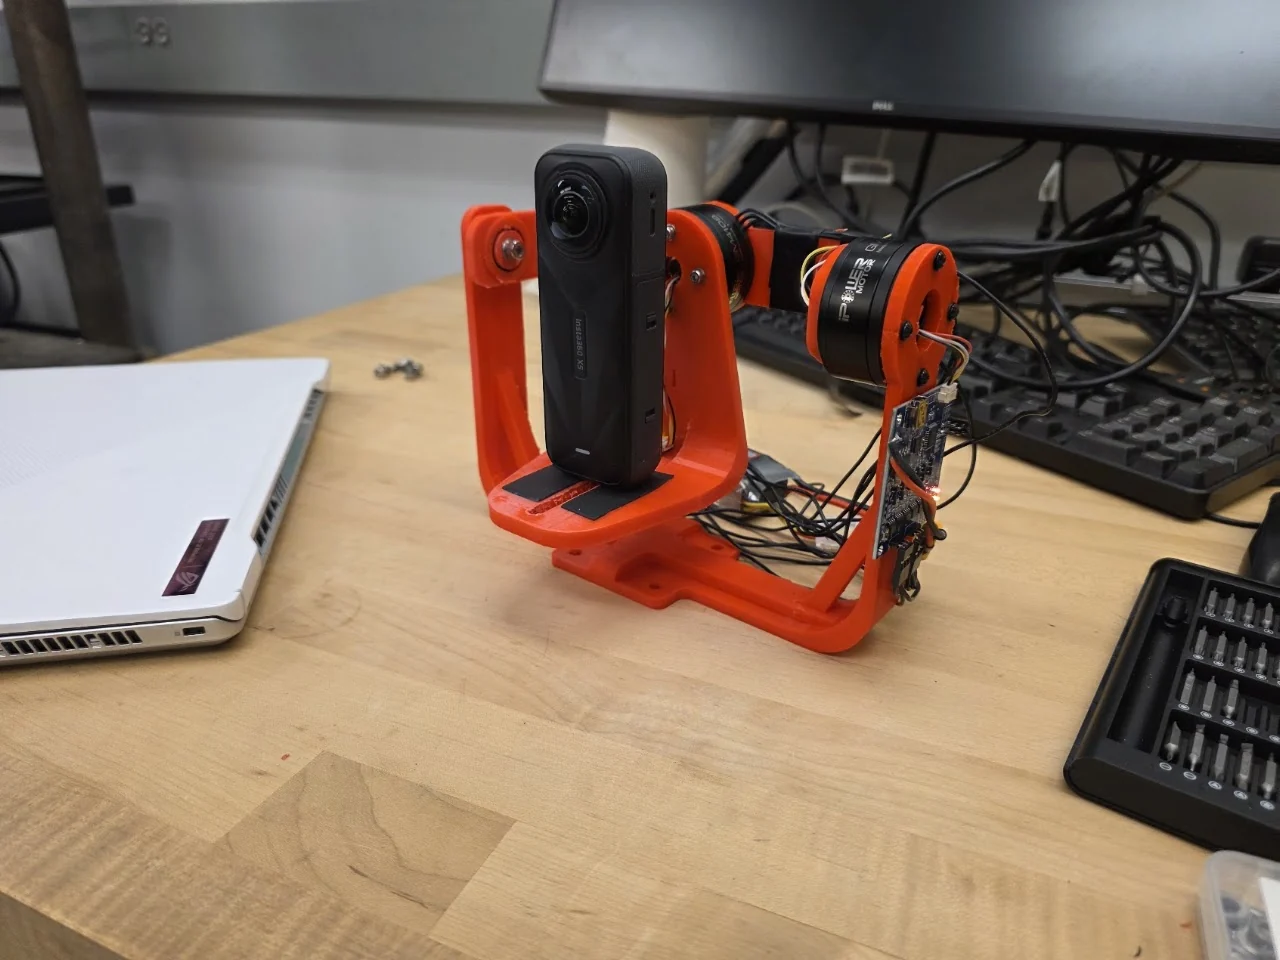
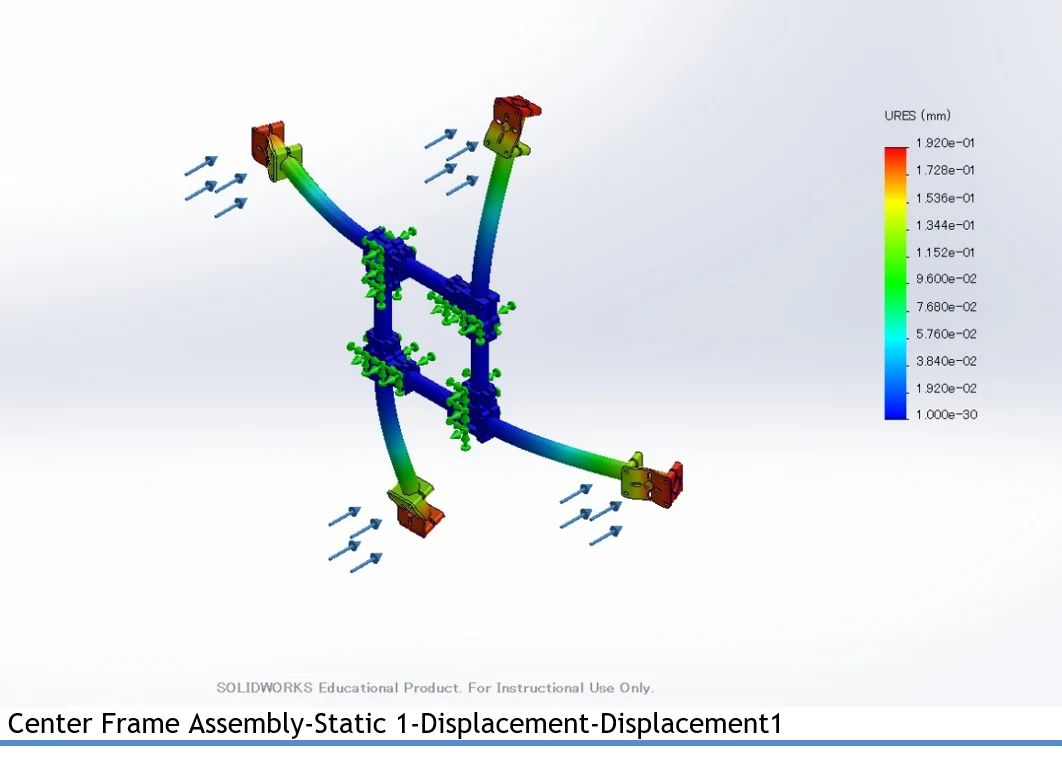
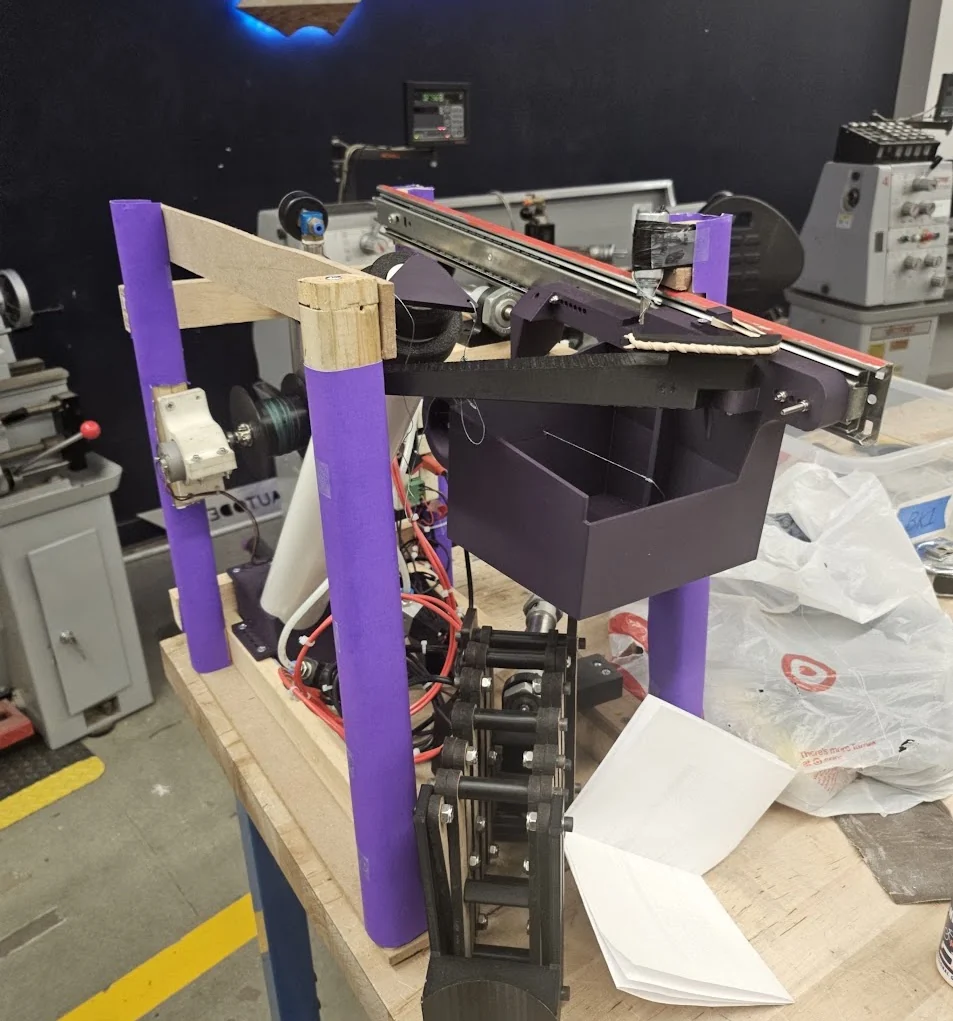
A height-adjustable camera payload developed by our capstone team for a quadruped robot. My contributions included concept selection, gimbal design and drawings, and structural analysis.

Mechanical design, Electromechanical integration, Validation
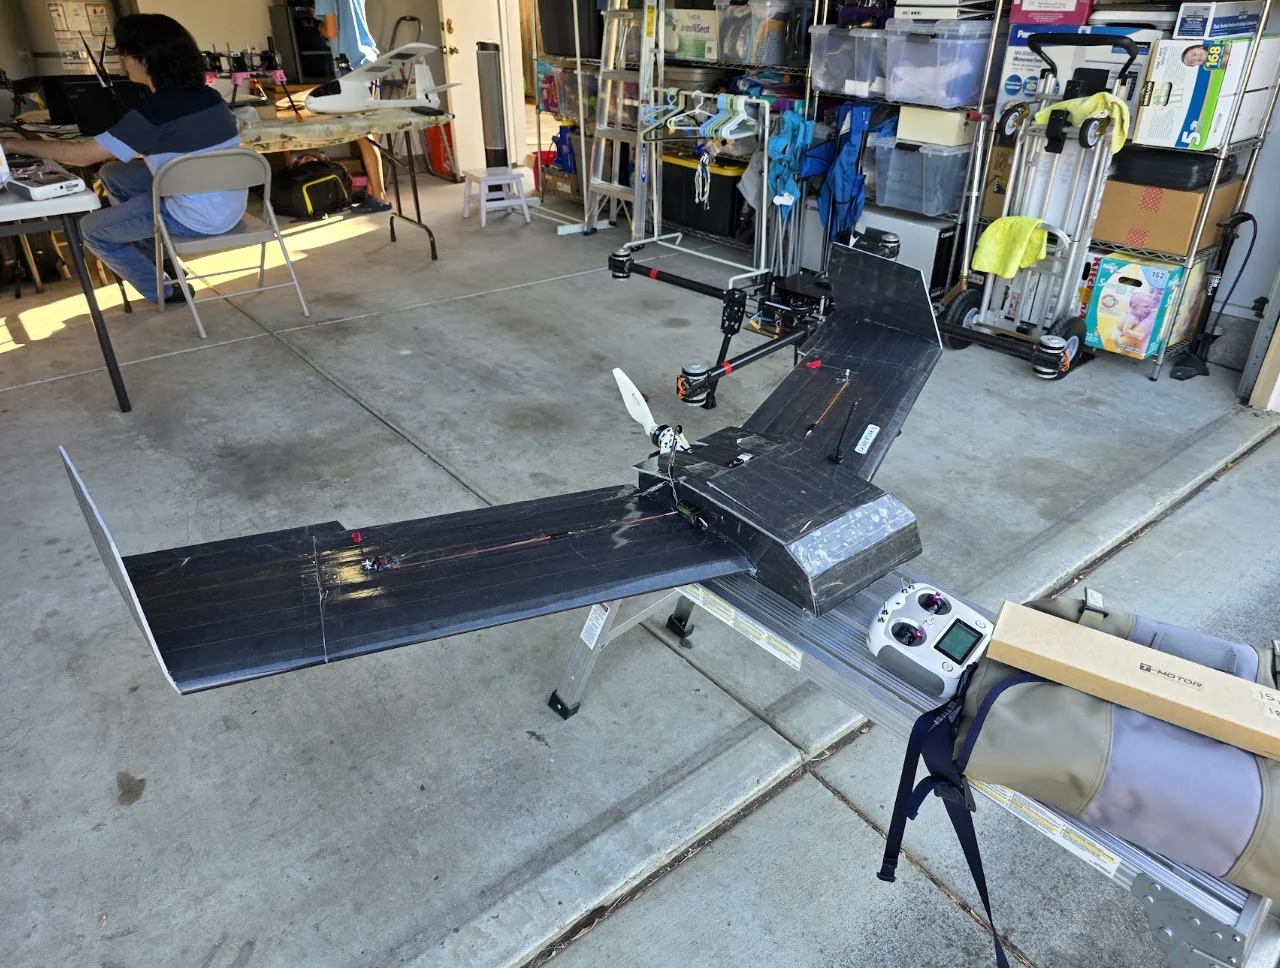
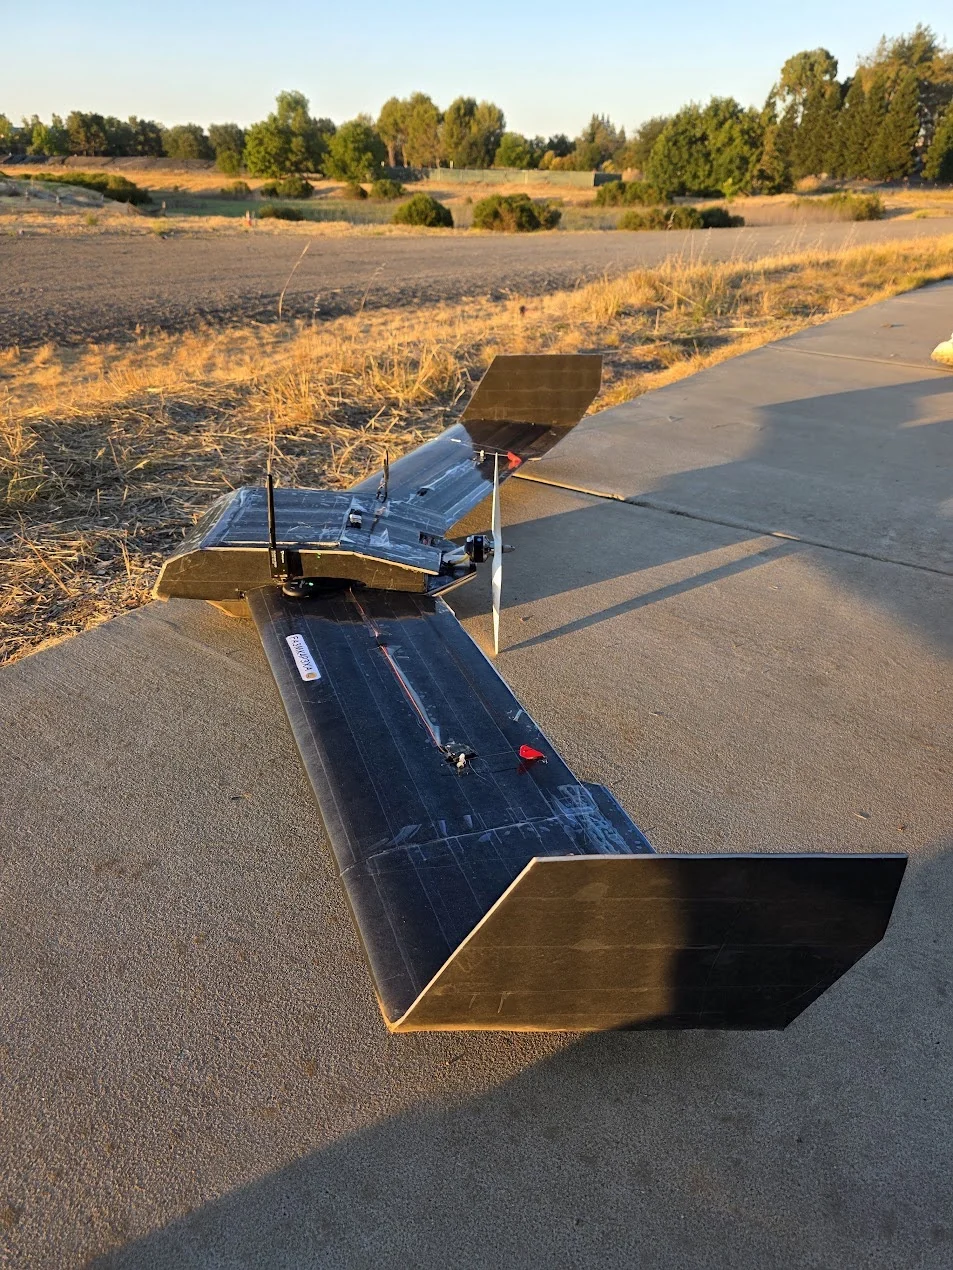
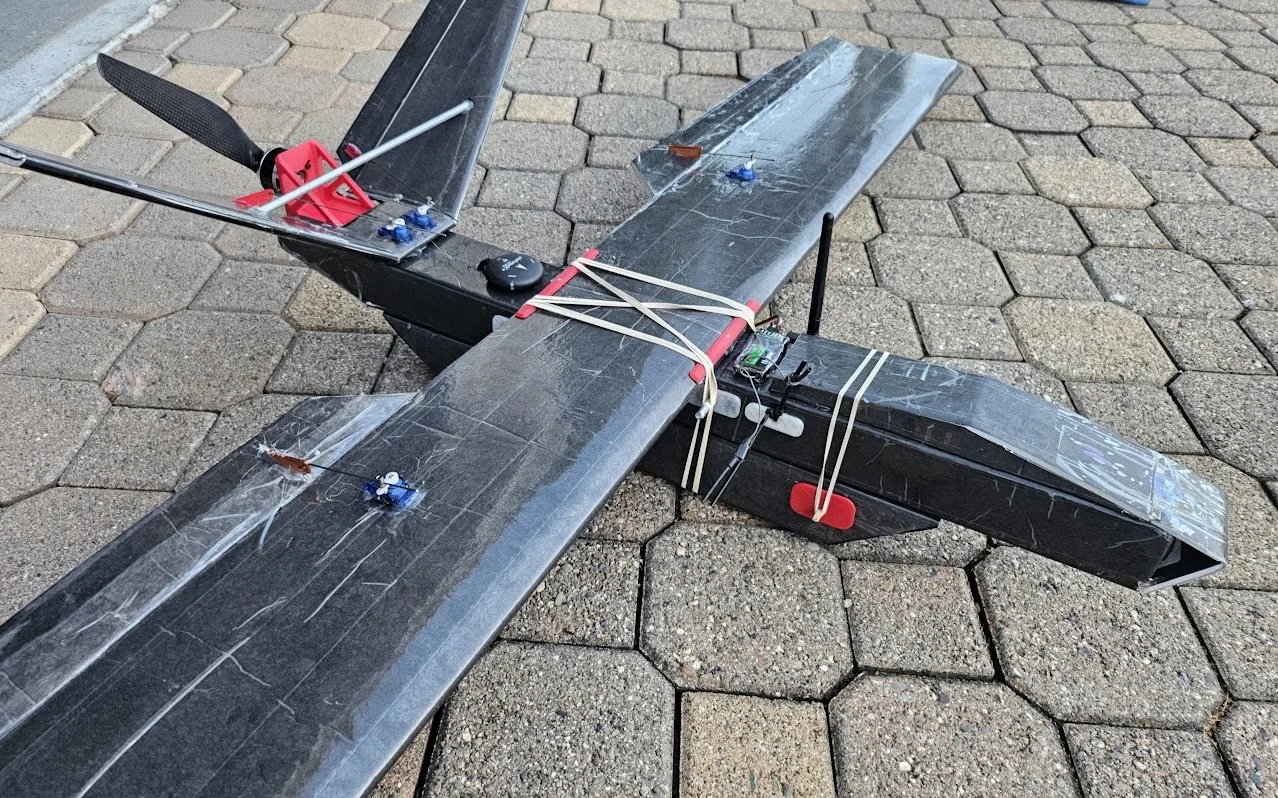
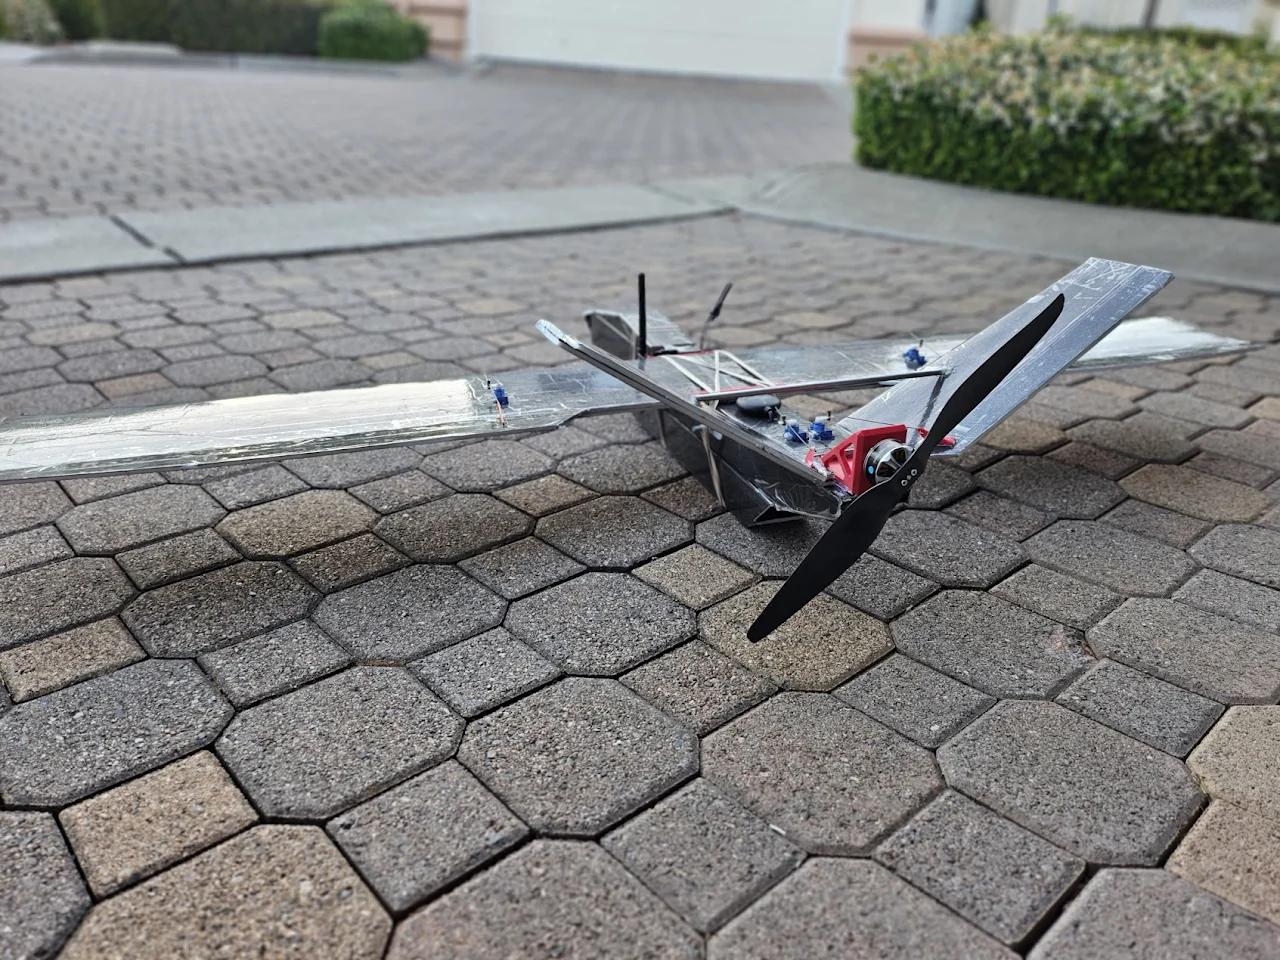
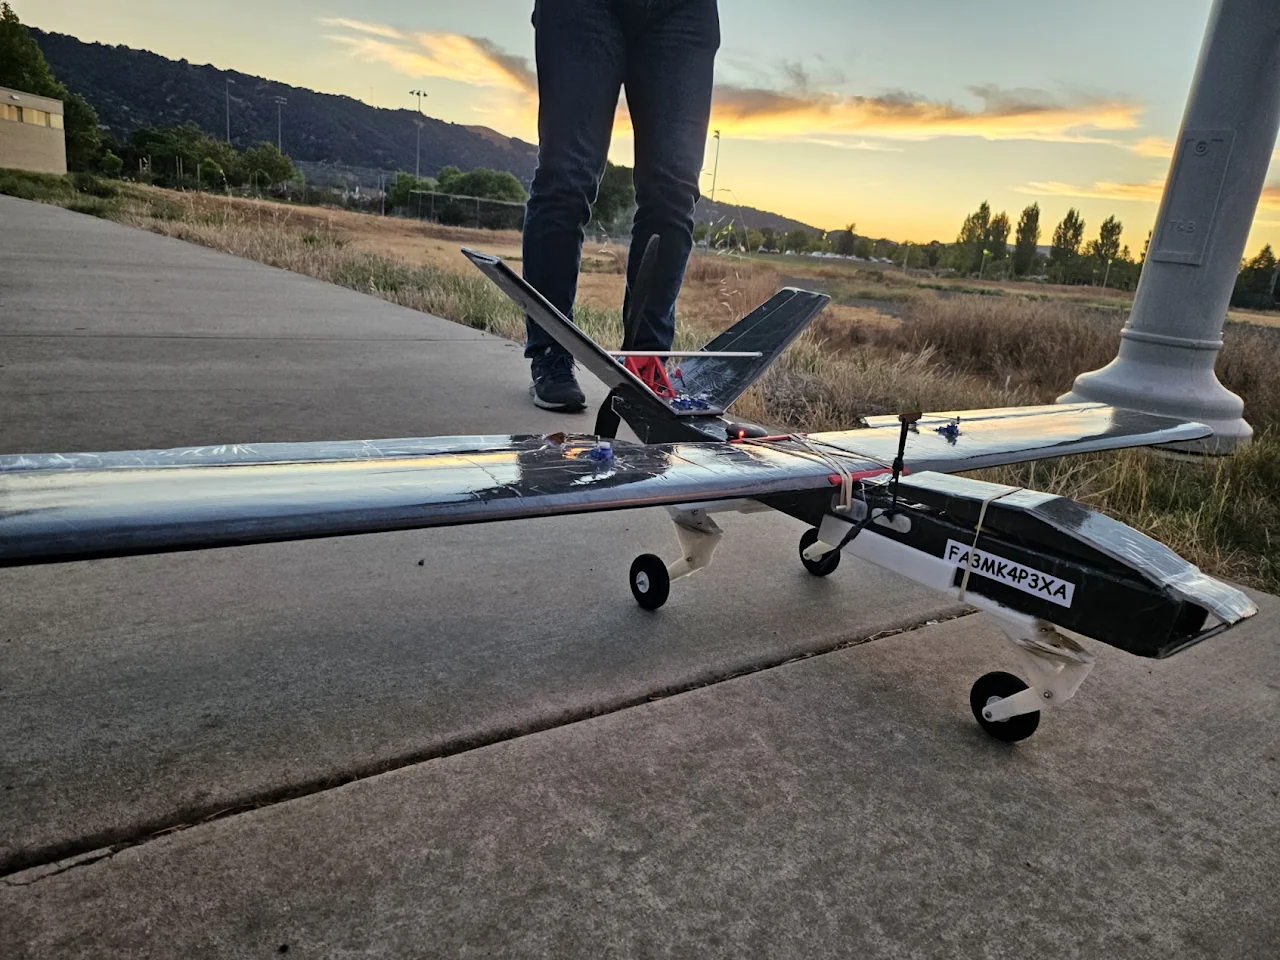
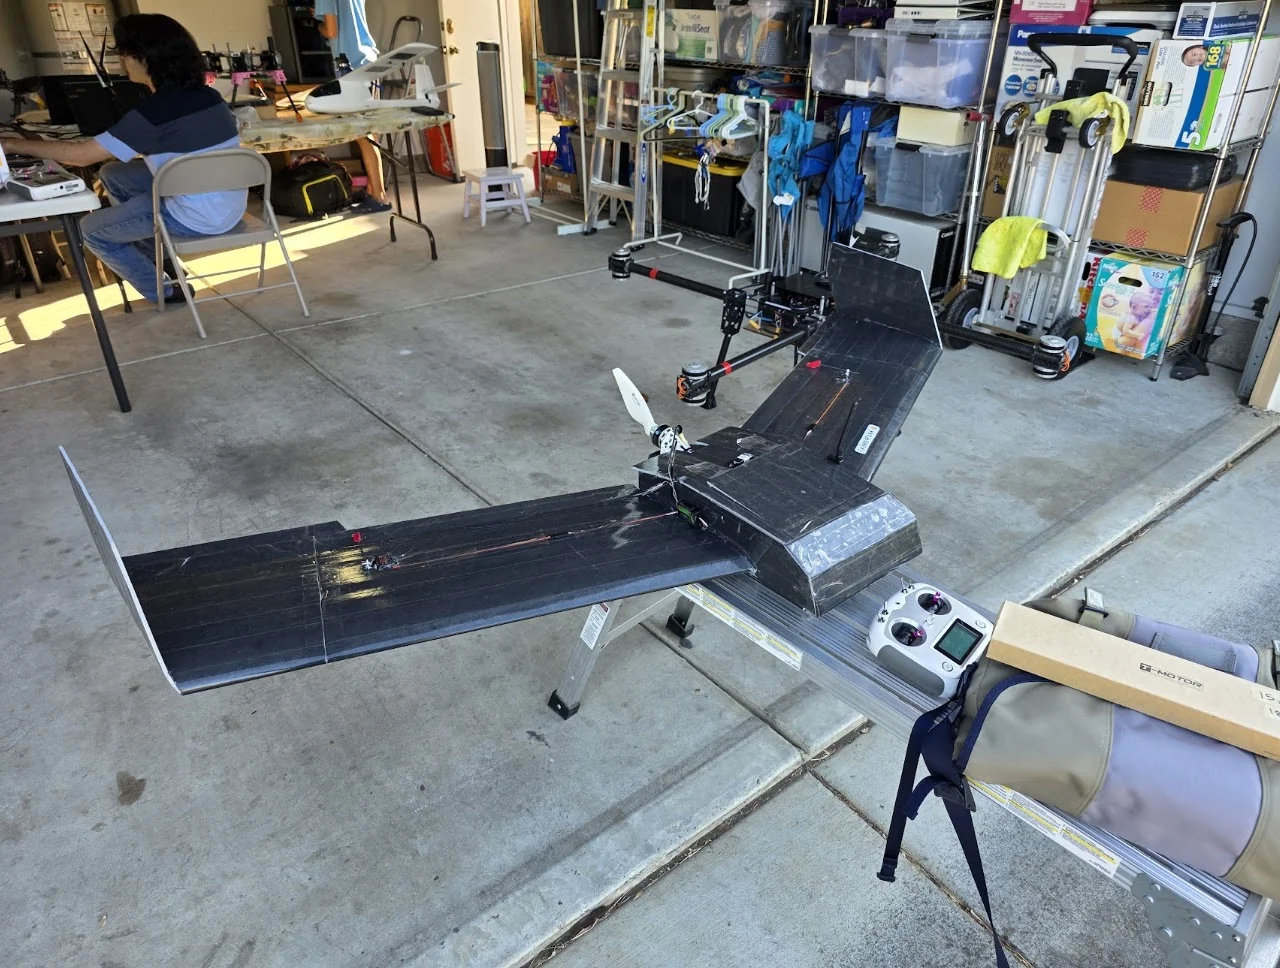
Custom flying-wing survey aircraft on a workshop stand
Independent UAV development · 2024–present

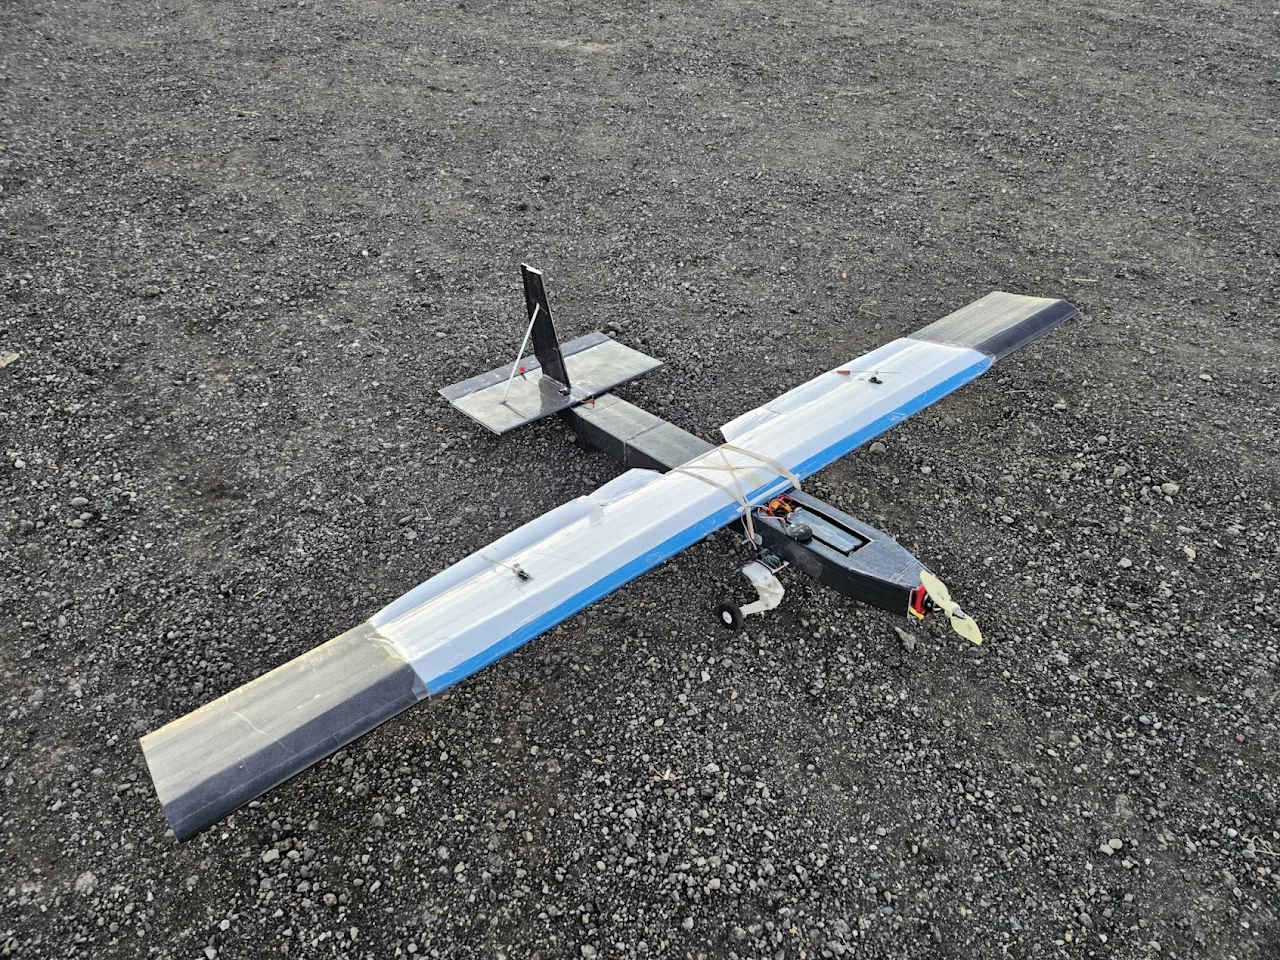
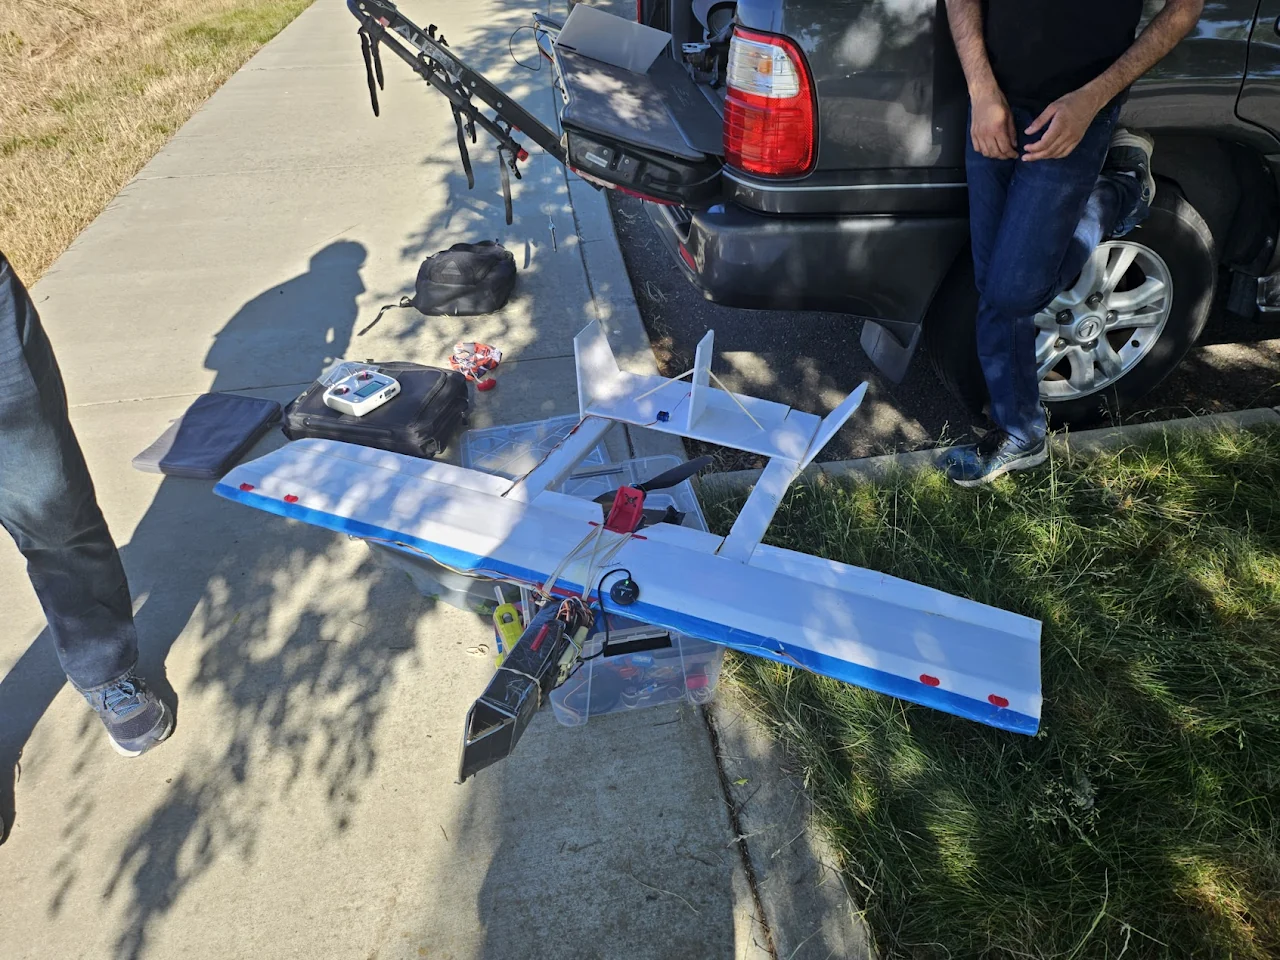
Autonomous survey aircraft

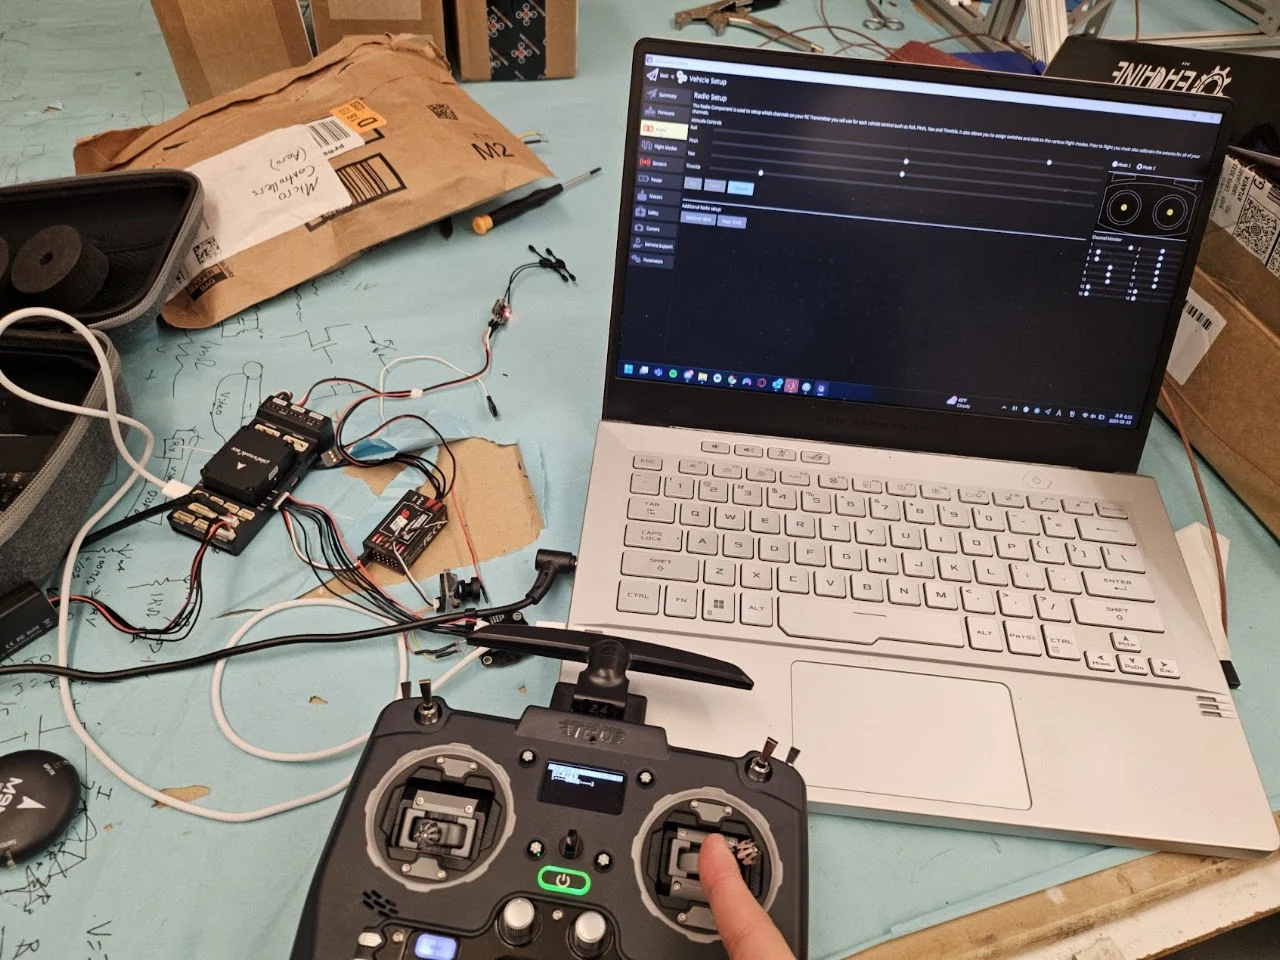
Independent fixed-wing UAV development, including airframe fabrication, custom landing gear, Pixhawk/PX4 integration, and flight testing.

Airframe design, Avionics, Flight testing

Engineering internship · Jun–Jul 2026

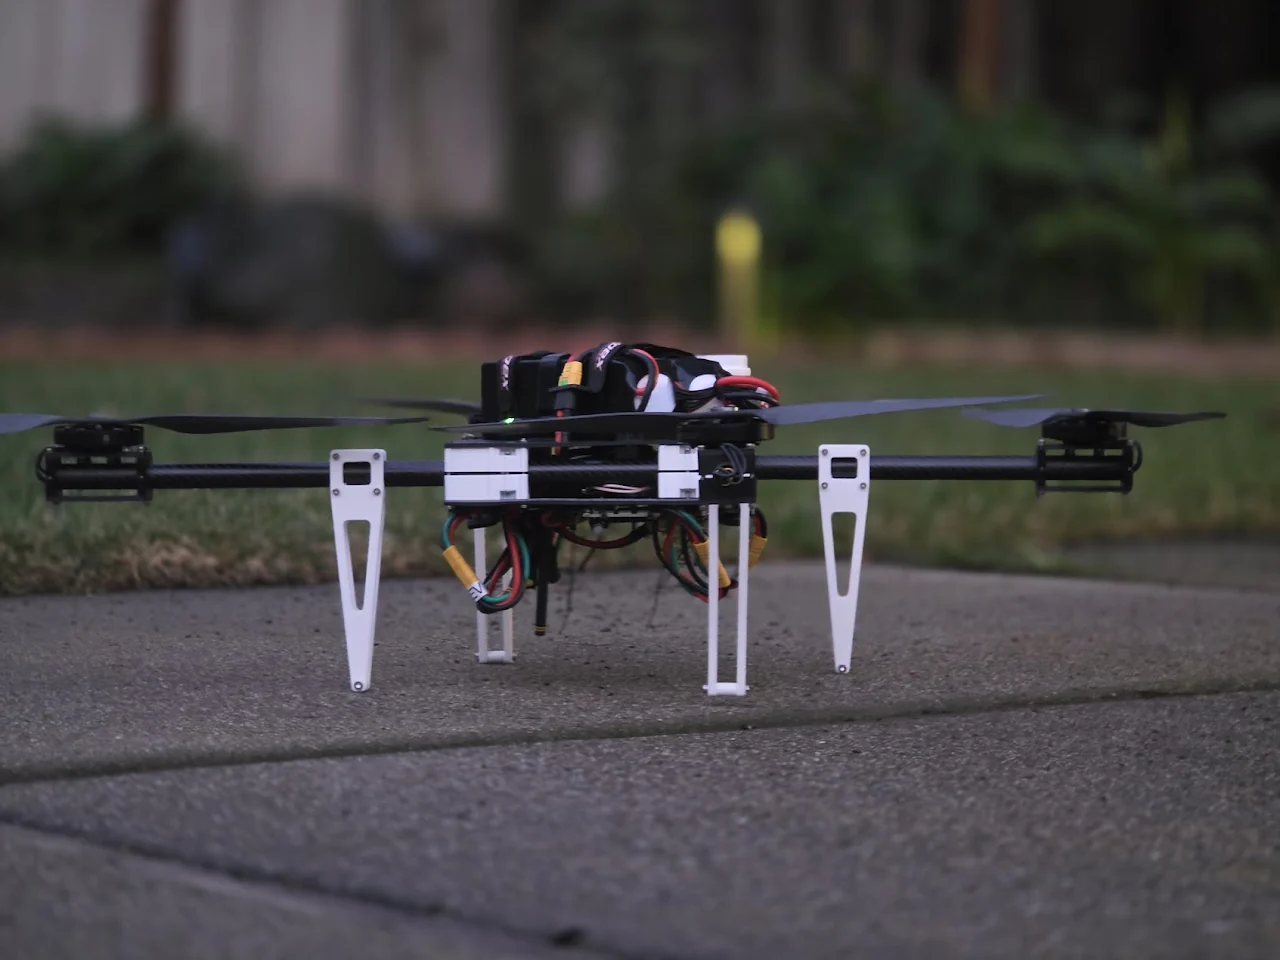
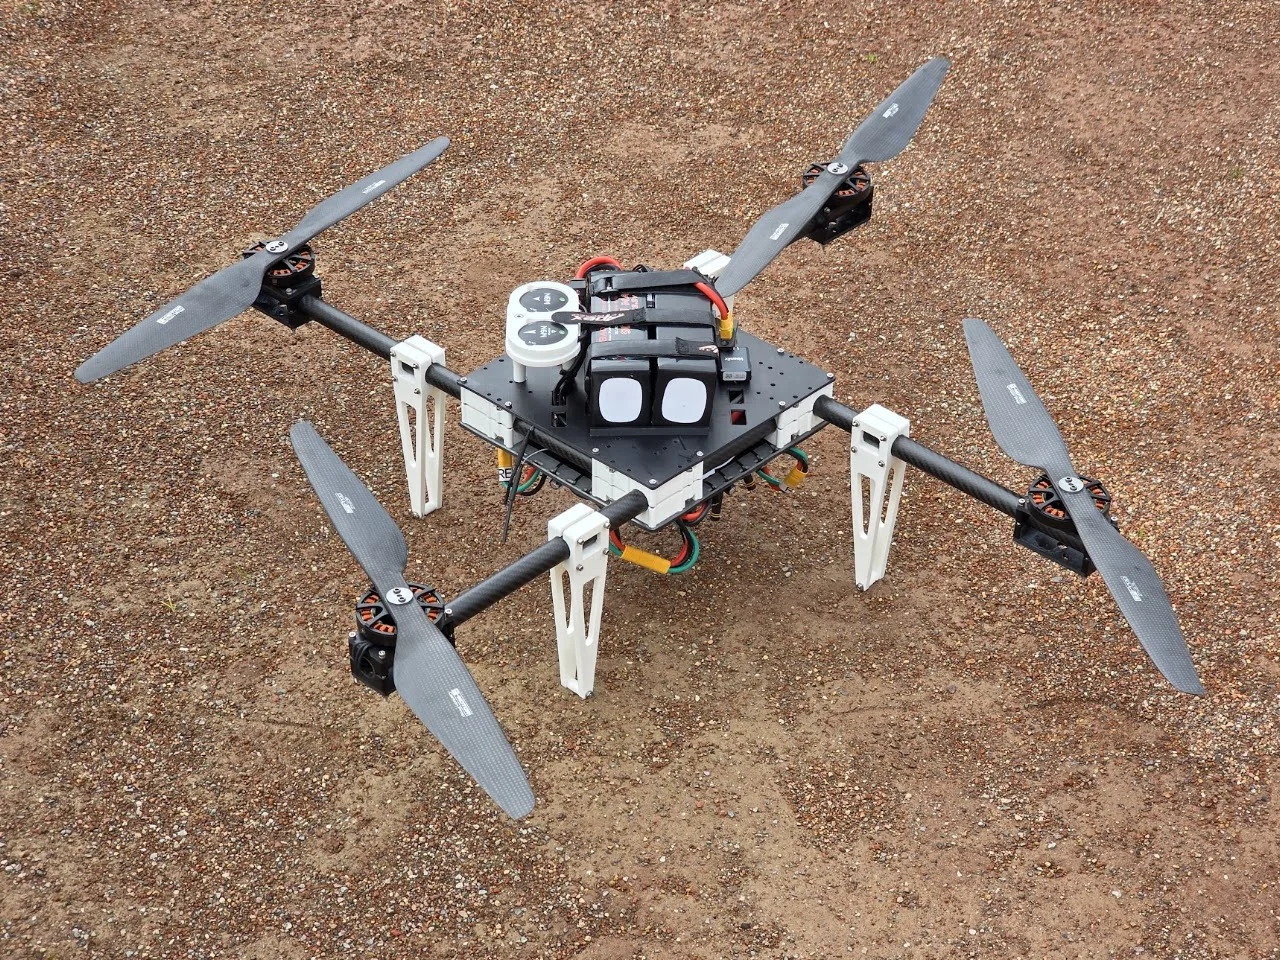
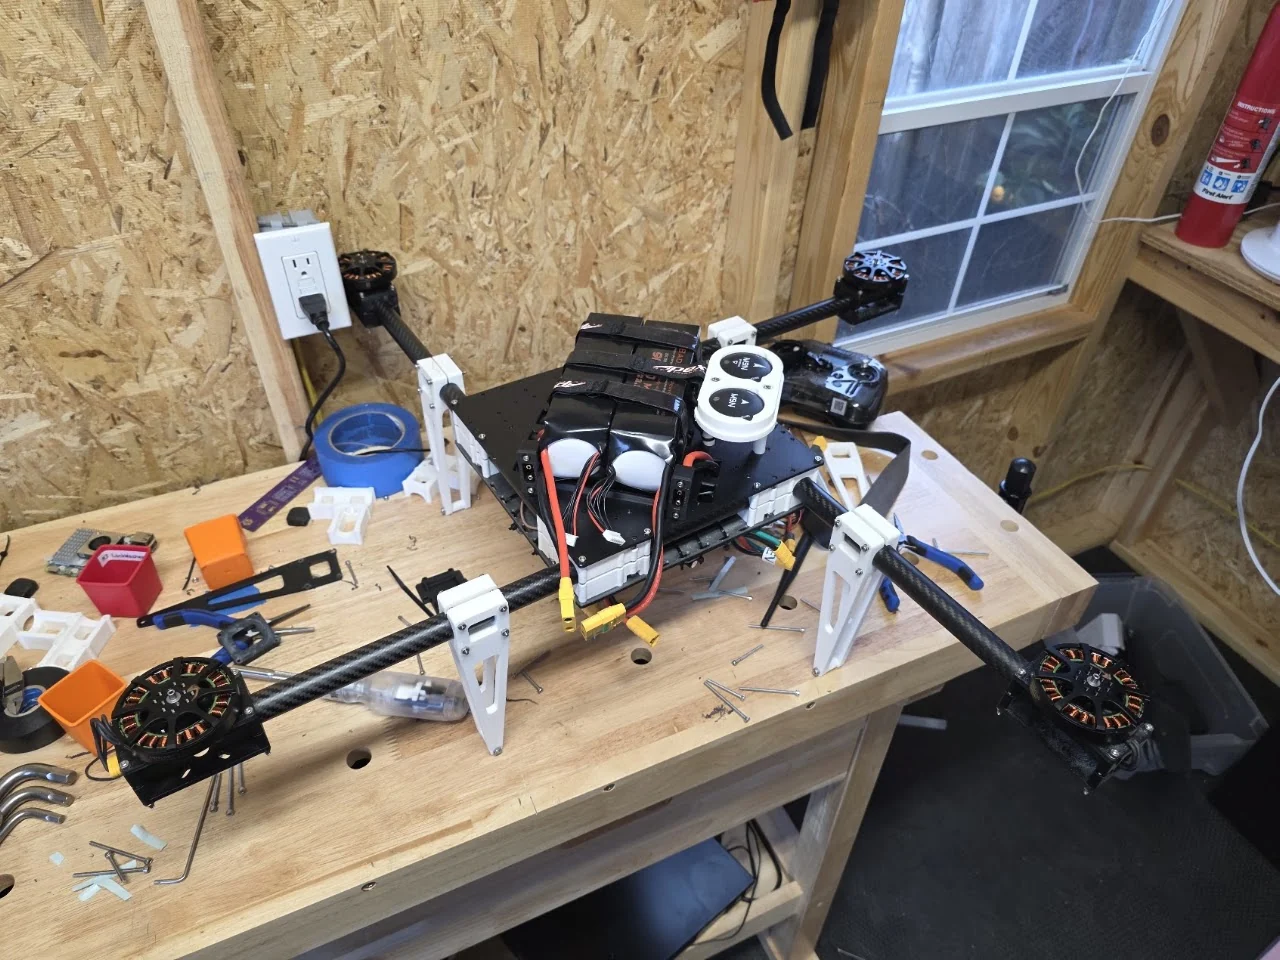
Heven UAV systems integration
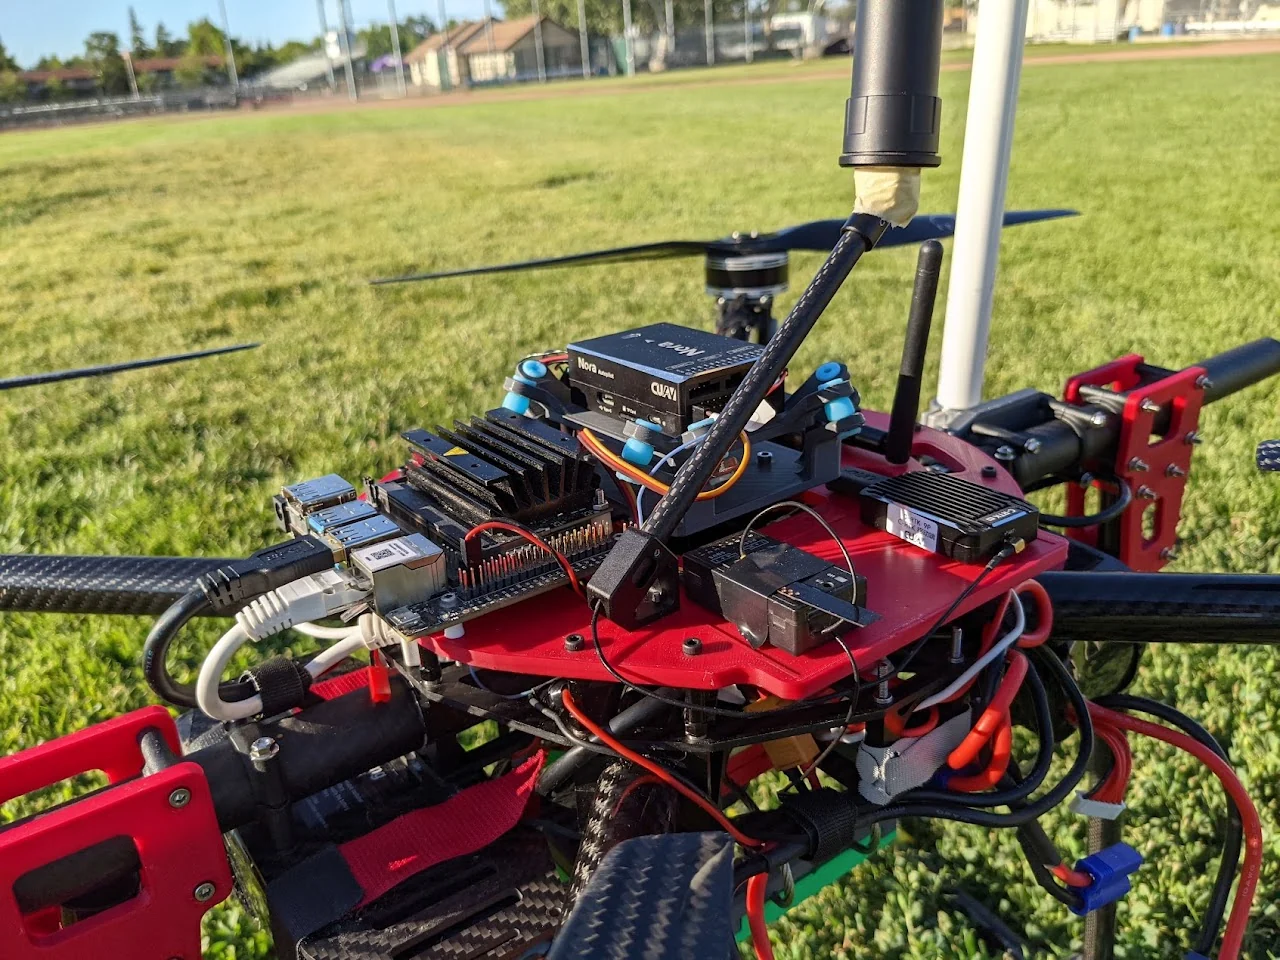
UAV subsystem integration, troubleshooting, and configuration documentation, alongside a Python tool I developed to estimate flight time and range.
UAV integration, Engineering software, Troubleshooting

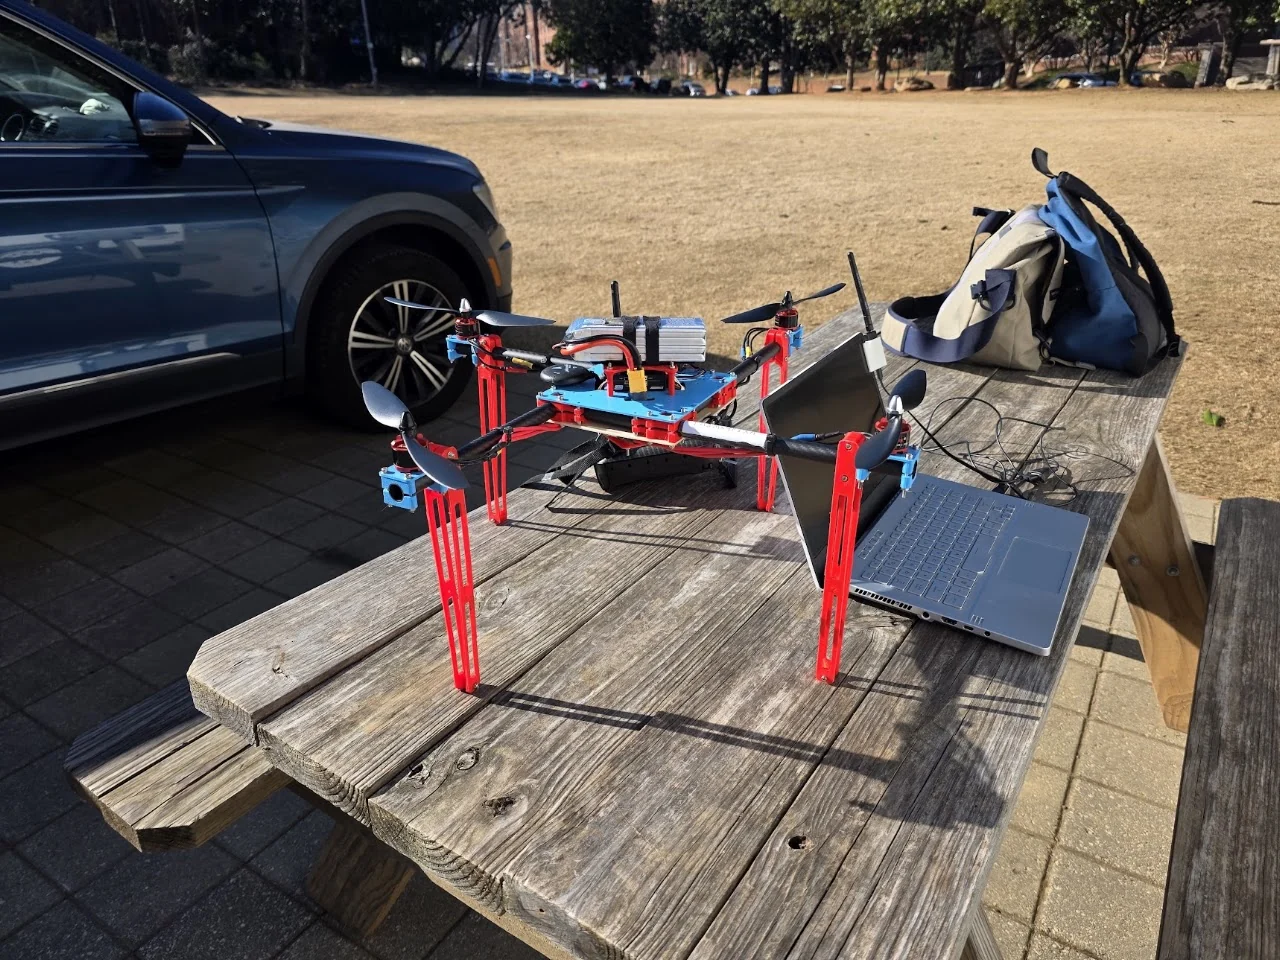
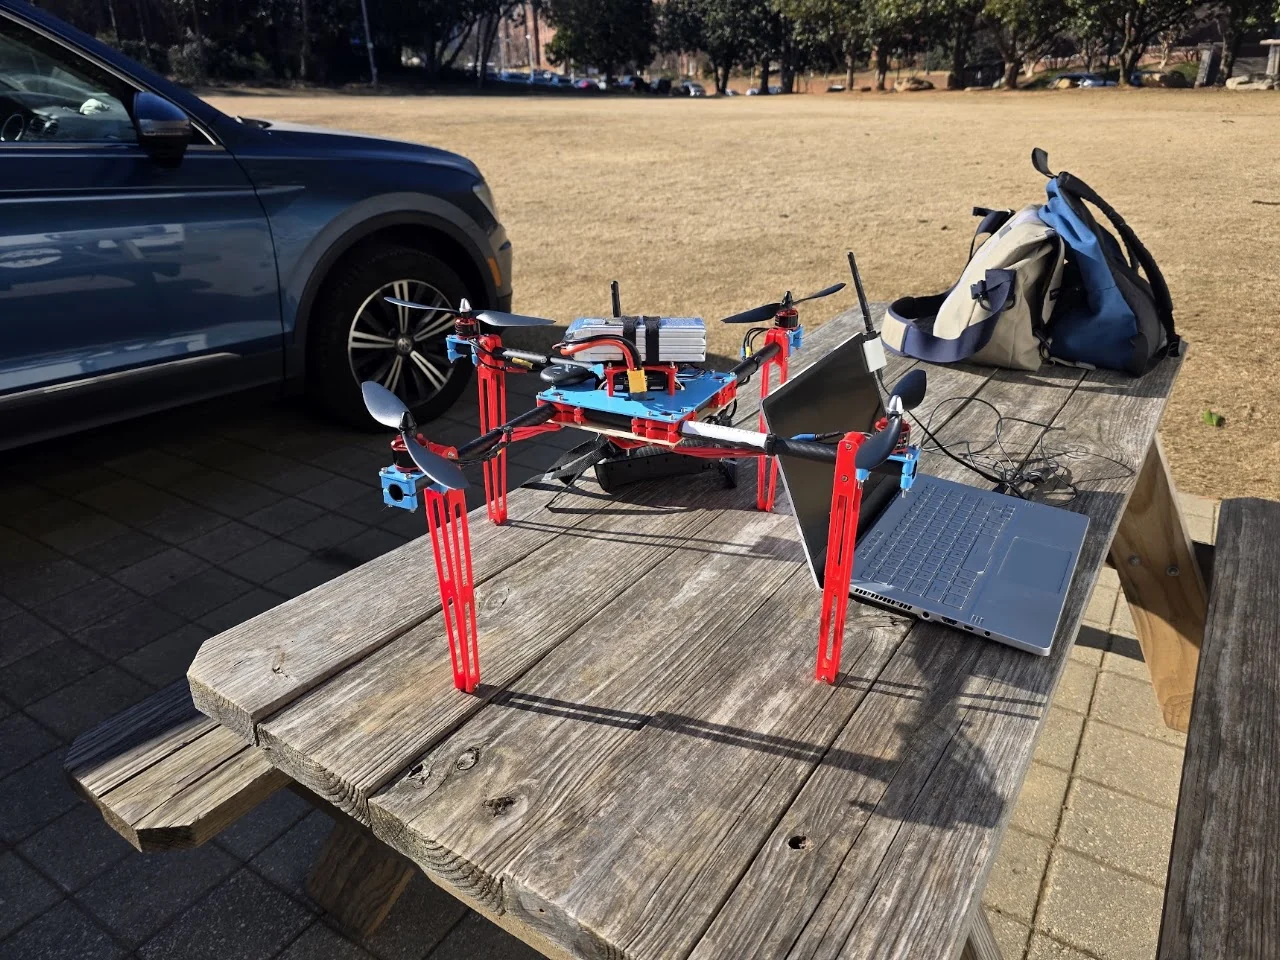
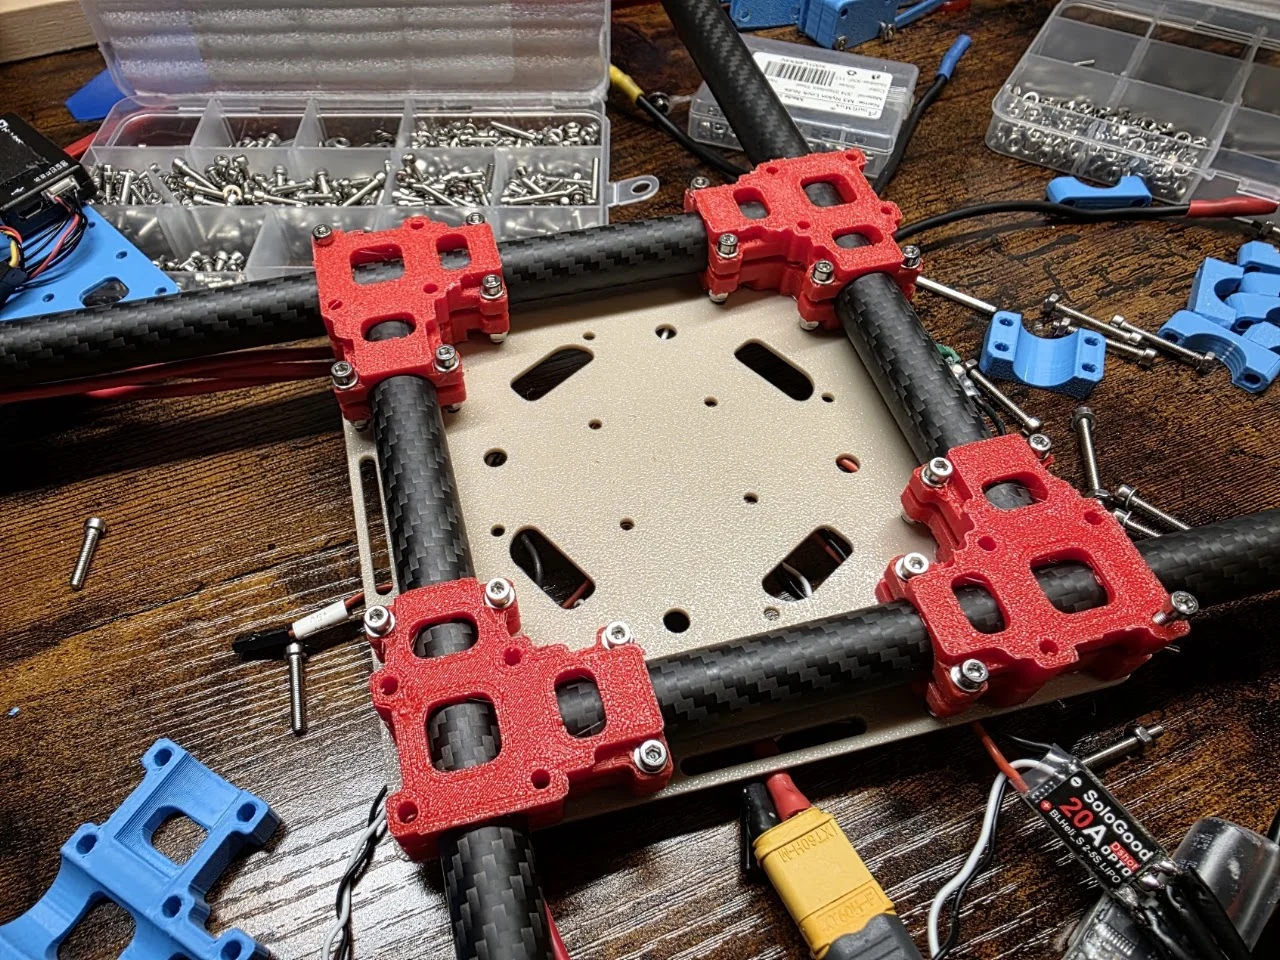
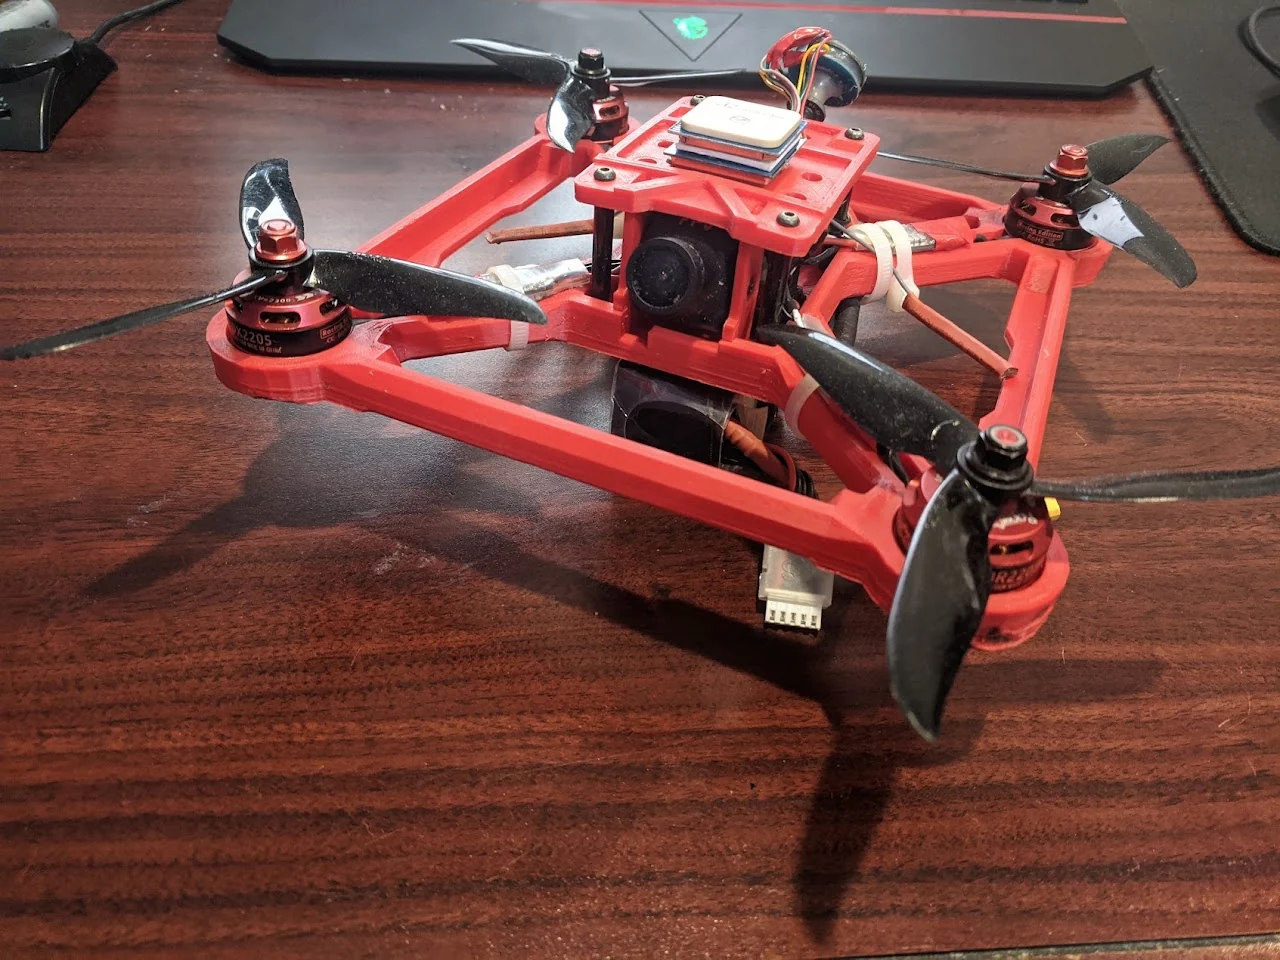
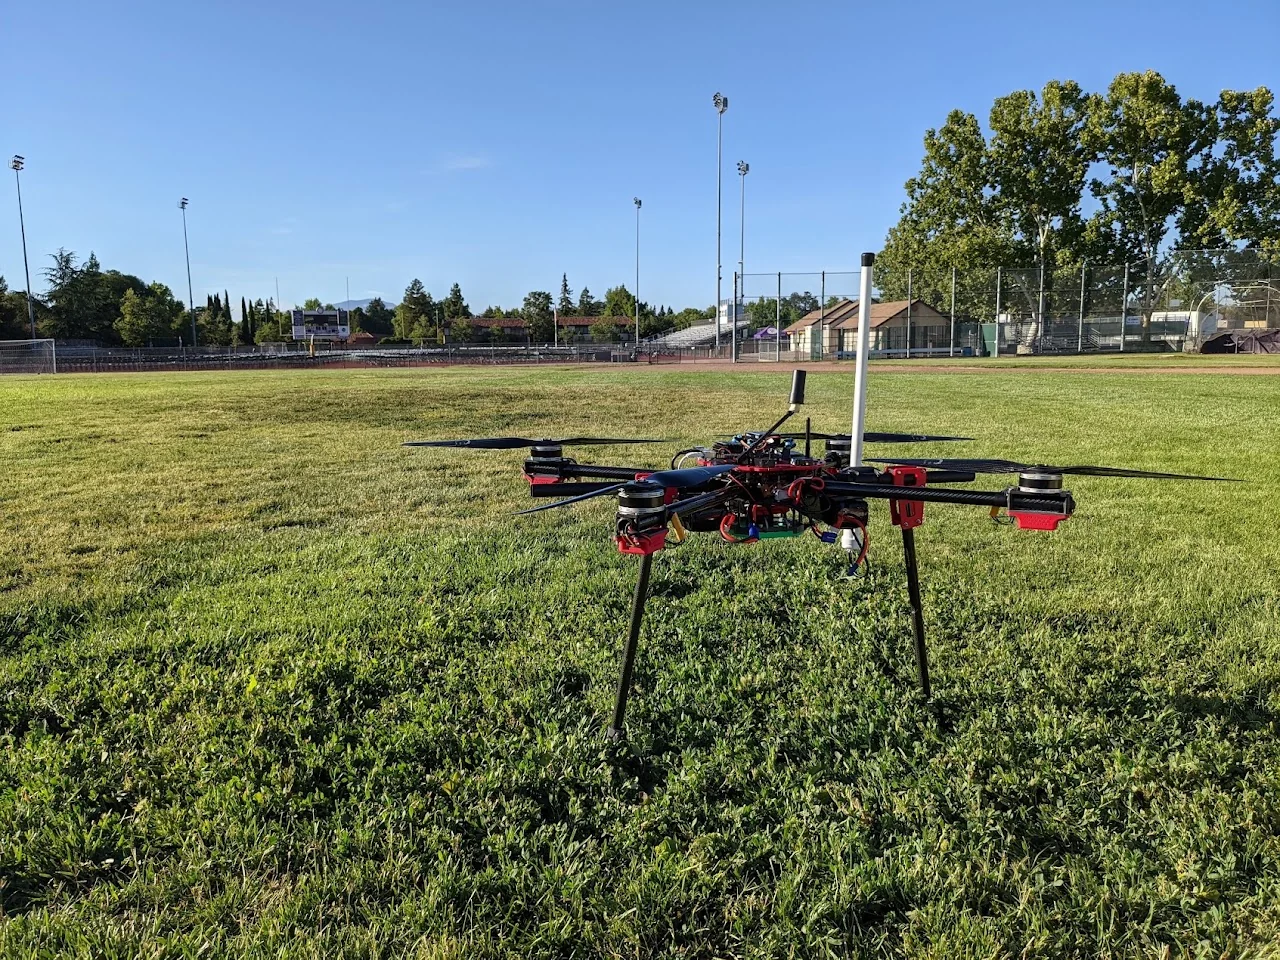
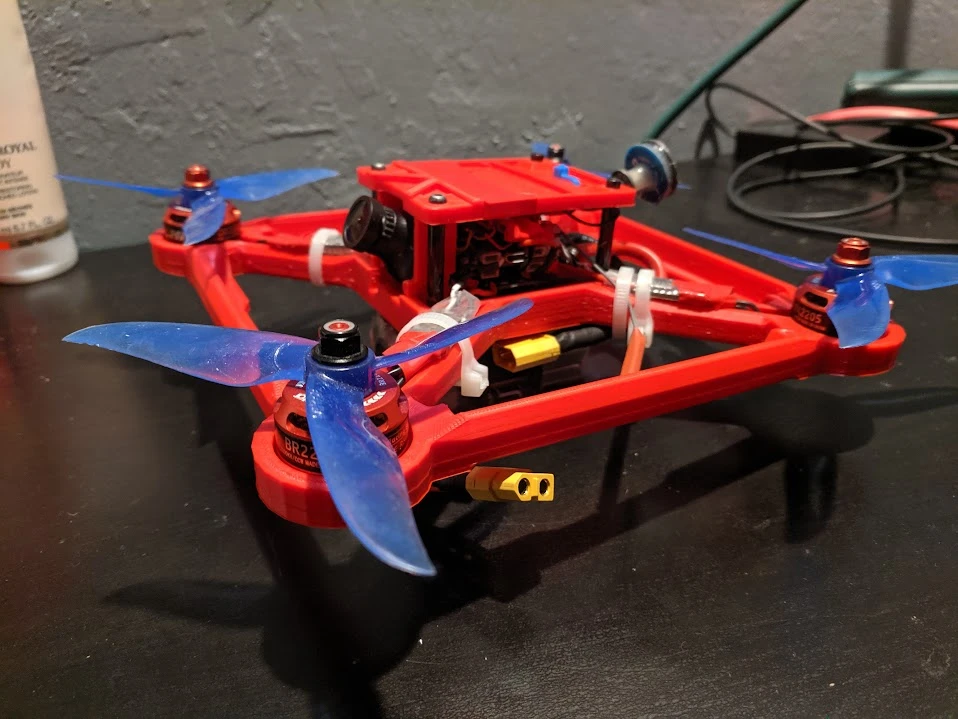
Assembled quadcopter with printed components and tube arms on a table outdoors
Personal hardware project

Modular quadcopter

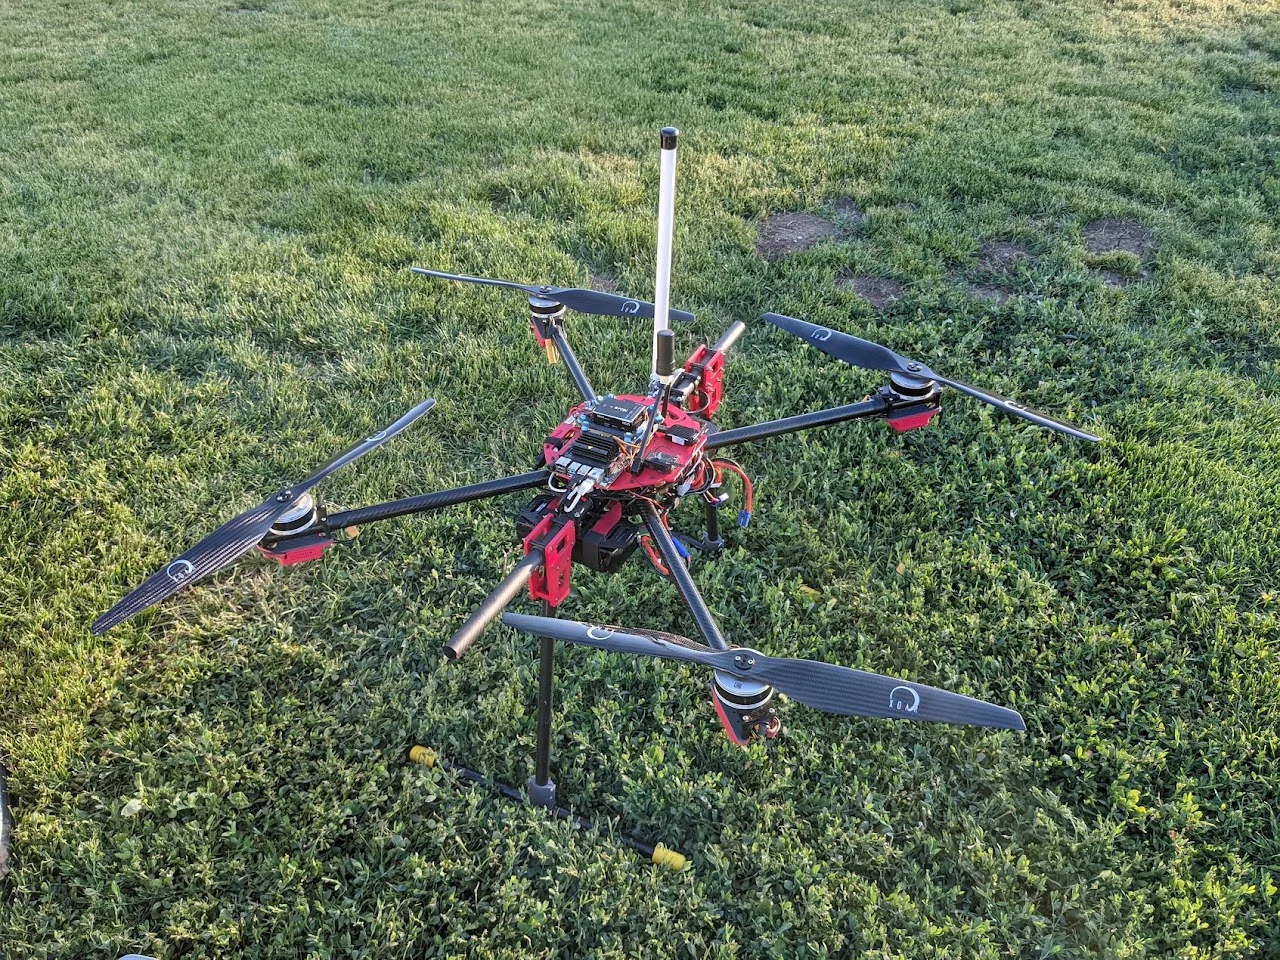
A custom quadcopter with modular printed components and tube arms. I designed the frame, integrated the electronics, and configured PX4.

Prototyping, PX4, Hardware integration
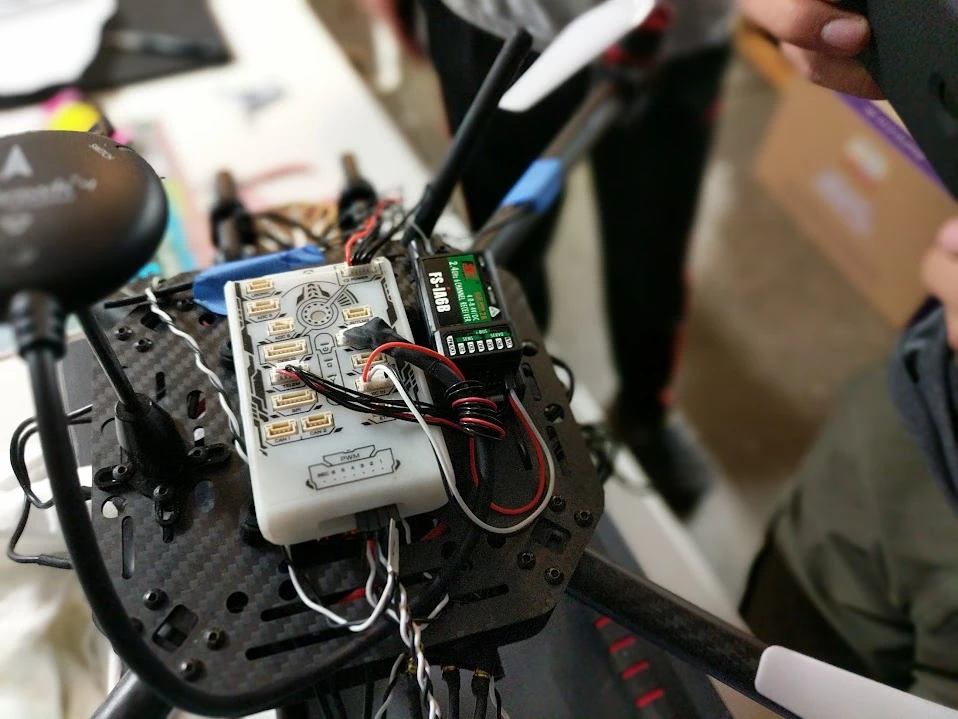
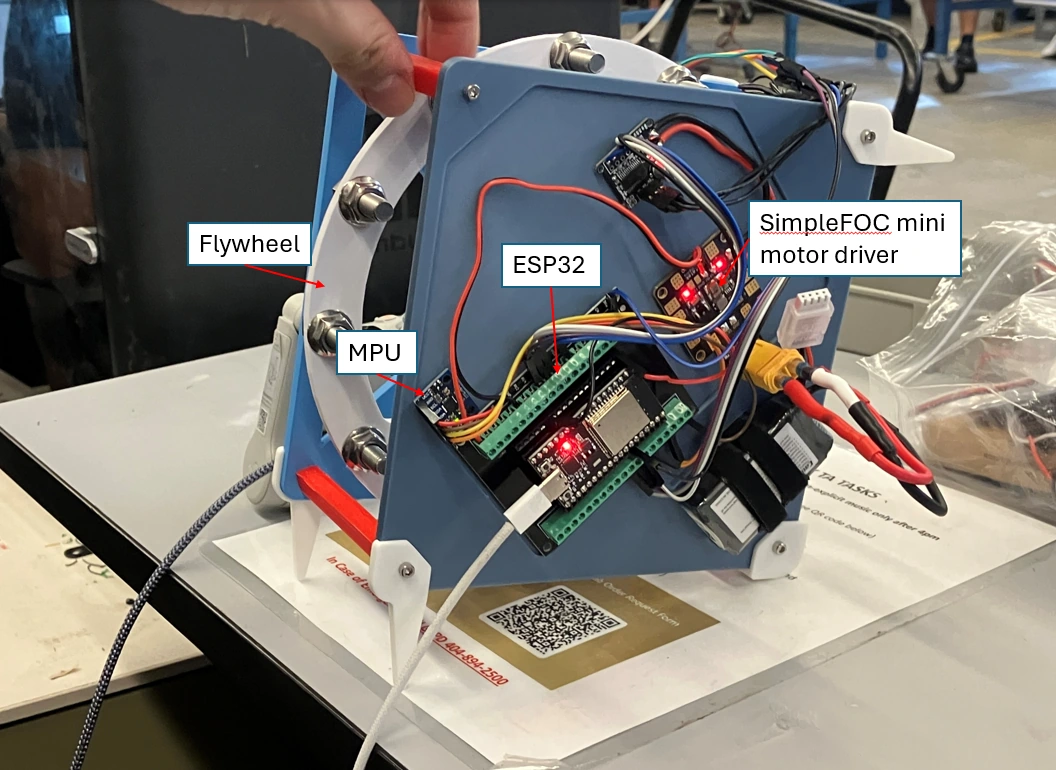
Sway Less prototype showing ESP32, IMU, and motor-driver integration
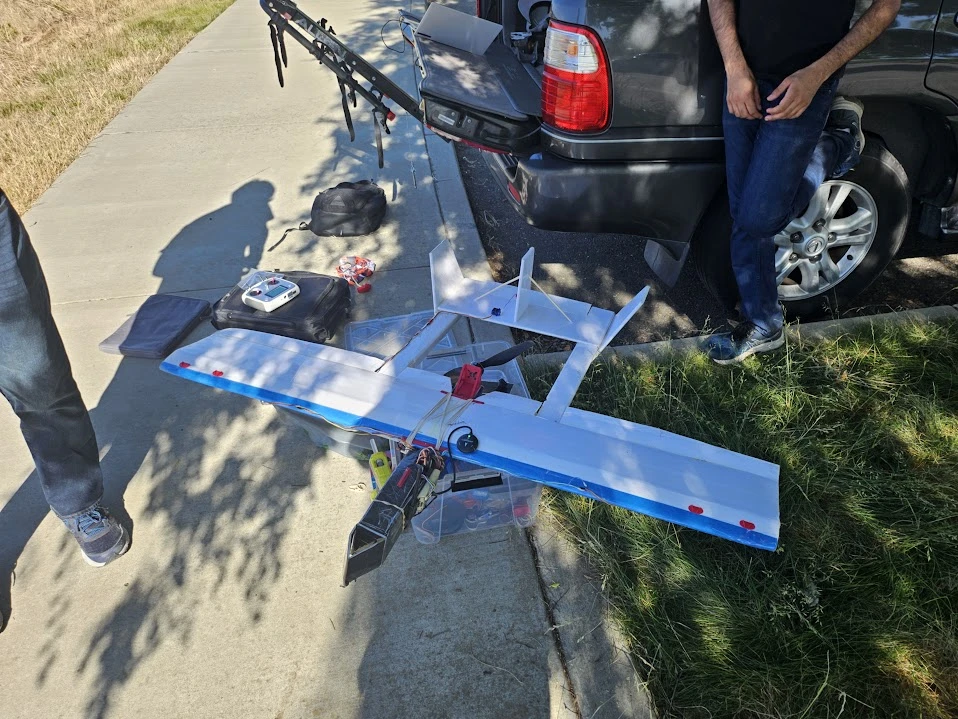
Team motion-controls project · Spring 2026

Sway Less reaction-wheel balancing system

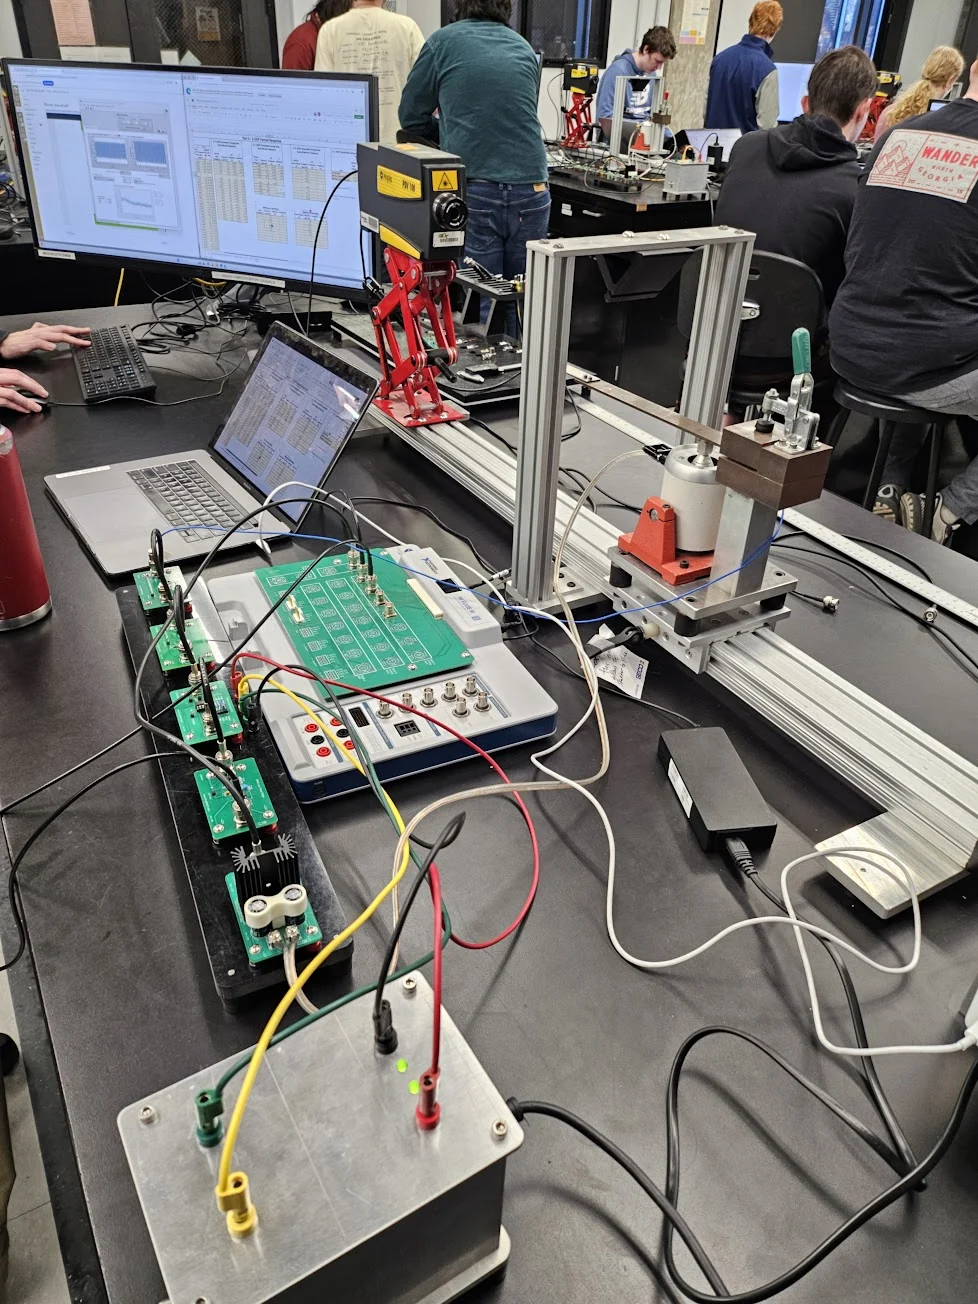
A reaction-wheel prototype combining ESP32 electronics, sensor feedback, and PID control. My work focused on electronics, controller design, mechanical assembly, and the project video.
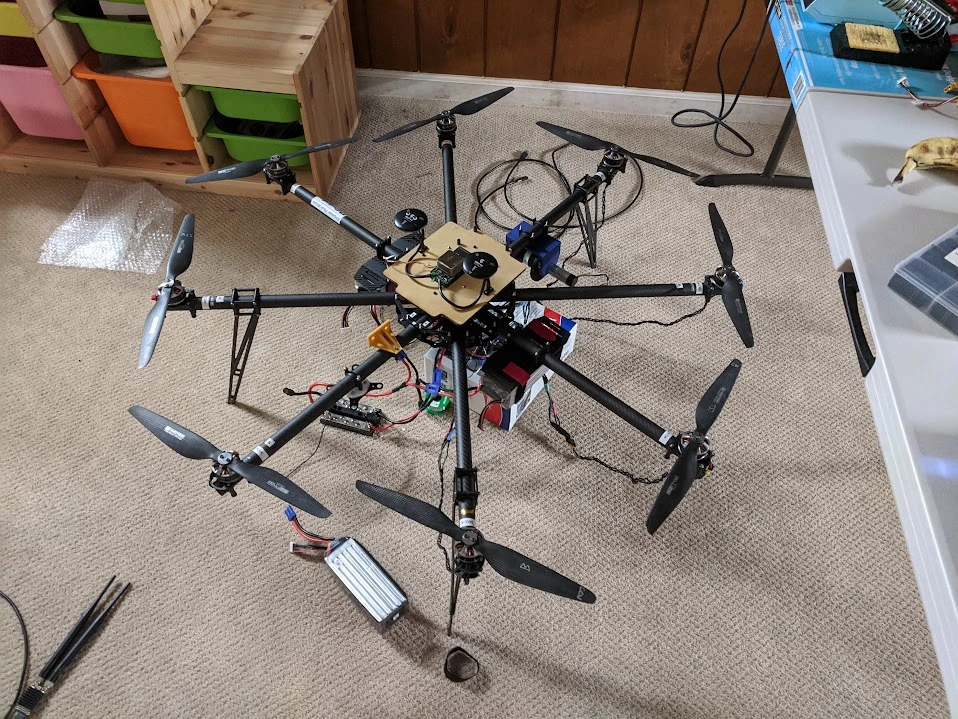
Motion control, Electromechanical systems, Sensor integration

Technical capabilities

Mechanical design & analysis

SolidWorks and Onshape for mechanisms, mounting interfaces, and structural analysis.

Camera Rig design

Prototyping & fabrication

FDM printing, laser cutting, airframe fabrication, and assembly.

Prototype development

UAV & electromechanical integration

Pixhawk, PX4, QGroundControl, sensors, actuators, and flight electronics.

UAV project overview

Testing & engineering tools

Hardware troubleshooting, flight testing, prototype testing, and Python modeling.

Survey Aircraft flight logs

Experience and education

More about my experience

  • Graduate Teaching Assistant · Georgia Tech

    ME 4853. Previously ME 2110 Undergraduate Laboratory Supervising Grader, January 2025–May 2026.

  • Multirotors Engineering Intern · Heven Aerotech

    I contributed to UAV integration and documentation and developed a Python performance estimator.

  • Airframe & Avionics Engineer · Experimental Flights VIP

    I led the VTOL subteam, working on structural concepts and Pixhawk integration.

Georgia Institute of Technology

M.S. Mechanical Engineering

Expected May 2027

B.S. Mechanical Engineering

May 2026 · Highest Honors

Get in touch

I'm seeking opportunities in mechanical engineering, UAVs, robotics, and systems integration. Please get in touch to discuss a role or my project work.

Seeking Spring 2027 internships and full-time roles starting Summer 2027.