Modular quadcopter
A custom frame with printed components, tube arms, and PX4 flight control
Mechanical design, Prototyping, UAV systems
Overview
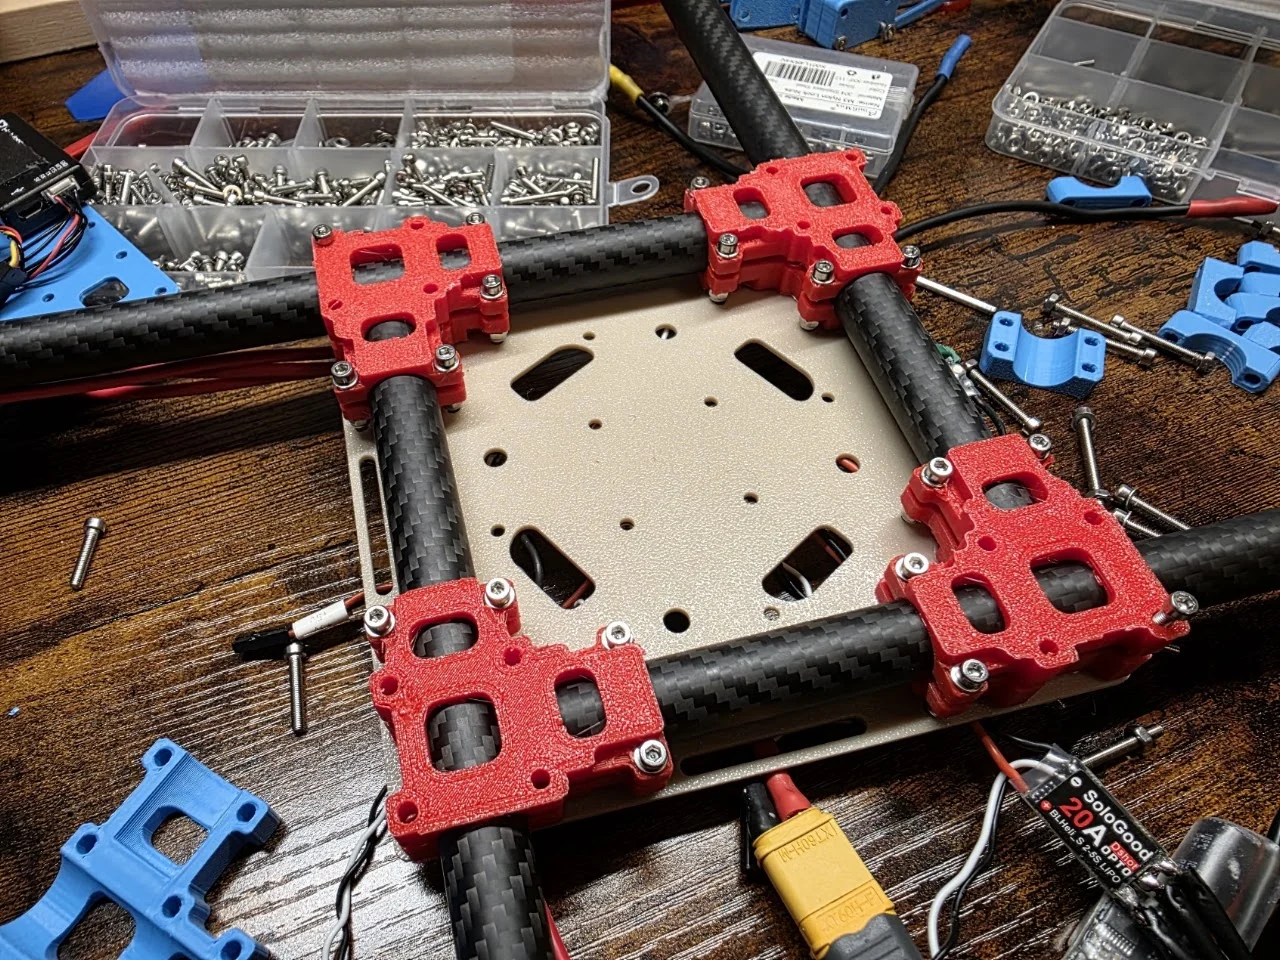
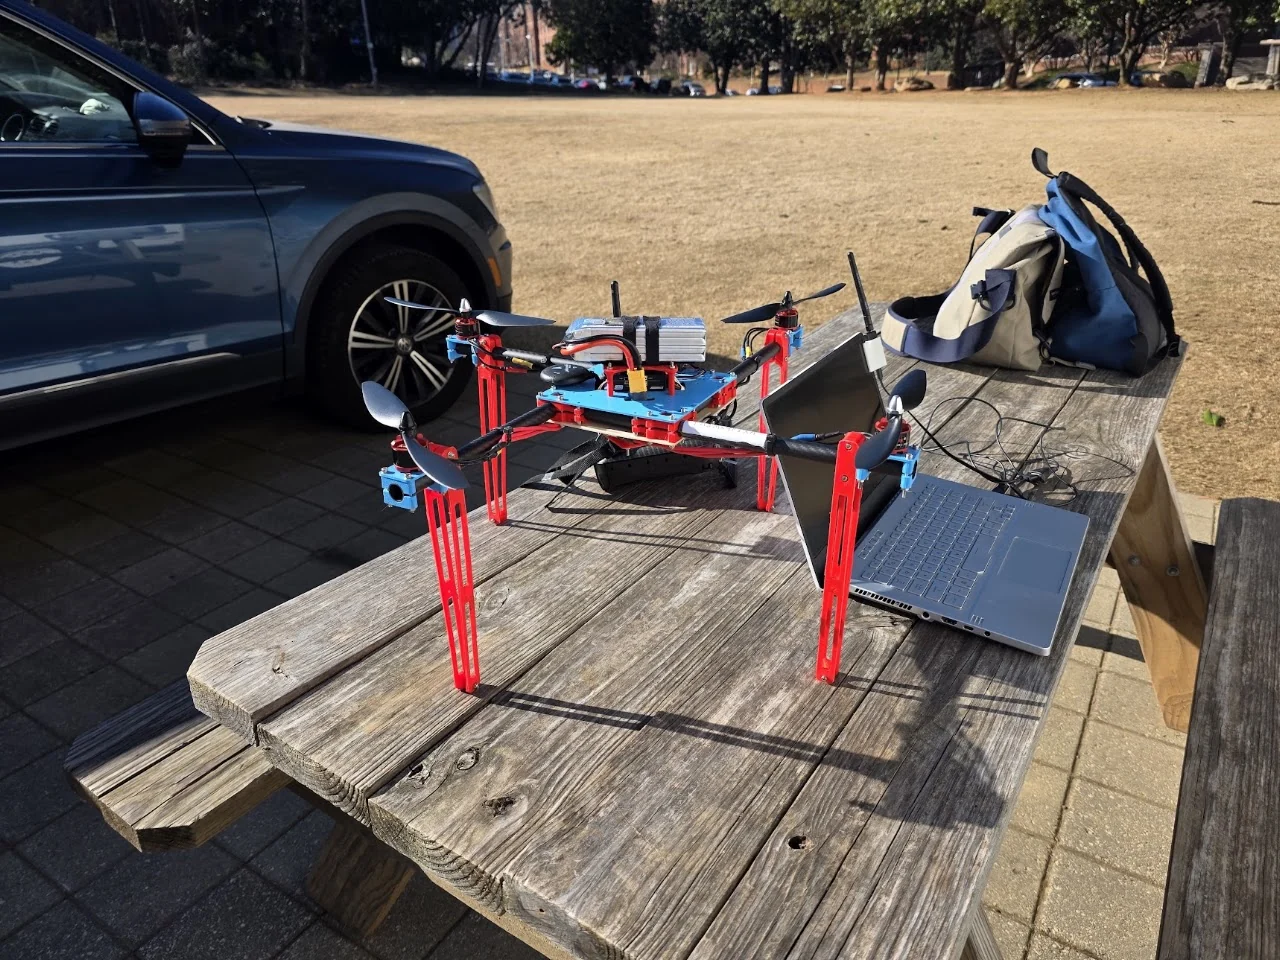
I designed and built a modular quadcopter intended for GPS-guided missions and straightforward component replacement. The frame combines FDM-printed plates, clamps, and mounts with tube arms.
I integrated the flight controller, GPS, and power distribution within the frame, then configured PX4 and carried out flight tuning.
Frame components and assembly